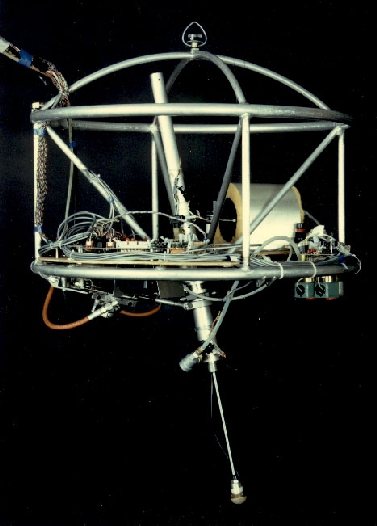
Carnegie Mellon University Leg Lab (Marc Raibert) · legged machine
3D One-Legged Hopping Machine
A one-legged robot with a pneumatic leg and hydraulic hip that hopped freely on an open floor, controlling hopping height, speed and body attitude separately. The work was funded by DARPA and published in 1984.
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
Showed that a robot could balance actively by hopping on a single leg in three dimensions, a foundation for later dynamic legged robots including Boston Dynamics' machines.
Real-world use
DARPA-funded research
Timeline
- Released
- Not yet
Maker
Carnegie Mellon University Leg Lab (Marc Raibert)University lab · founded 1980 · Pittsburgh, Pennsylvania, USADARPA research contracts
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current machines.
- No Wikipedia article of its own yet
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs
- How it runs
- Assisted. Its controller kept it balanced and hopping on its own while an operator could set the speed and direction it travelled.
- Actuators & motors
- A simple pneumatic springy leg positioned by a hydraulic hip.
- Sensors & vision
- Not detailed in the sources used.
- Compute
- Off-board computer running a three-part controller (hopping height, forward speed, body attitude).
- AI & software
- Raibert's decomposed balance controller, generalised from the earlier planar (2D) hopper; let the machine hop in place, run at a set speed and follow a simple path without support.
- Other details
- Ran and balanced on an open floor with no mechanical constraint; described in CMU-RI-TR-83-01 and in the International Journal of Robotics Research (June 1984).
From the maker
3D One-Legged Hopping Machine is the only machine from Carnegie Mellon University Leg Lab (Marc Raibert) in the atlas.
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Research machine (one)
- Sold or delivered
- not sold
- Where it is sold or used
- Carnegie Mellon University Leg Lab, Pittsburgh; the lab moved to MIT in 1986
- Customers and pilots
- DARPA-funded research
Sources
Figures come from a published paper. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use