Tokyo Institute of Technology (Hirose lab) with HiBot · legged machine
ACM III
Active Cord Mechanism
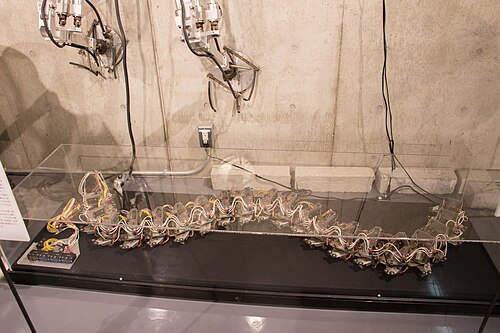
A chain of powered joint units that glided across a flat floor using the same push-against-the-ground principle as a snake. It relied on a large tethered control system, so it was not self-contained.
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
The Tokyo Tech lab credits it as the first machine to reproduce the gliding, undulating locomotion of a real snake (the lab's own claim).
Real-world use
None
Timeline
- Released
- Not yet
Maker
Tokyo Institute of Technology (Hirose lab) with HiBotUniversity lab · Tokyo, JapanPublic attention
A historic robot: no longer sold or in use, so it is not ranked against current machines.
- No Wikipedia article of its own yet
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Other movement
- Actuators & motors
- Serially connected active joint units that bend the body to produce snake-like undulation; passive wheels along the body.
- Compute
- Controlled through an extensive tethered external control system (no on-board computer).
- Battery & power
- None; power and control came through the tether.
- Other details
- Demonstrated in 1972 that a machine could glide across a flat floor on the same principle as a snake. The self-contained successor ACM-R1 (1995-99) was about the same size and weight and moved more than twice as fast.
From the maker
ACM III (Active Cord Mechanism) is the only machine from Tokyo Institute of Technology (Shigeo Hirose lab) in the atlas.
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Research prototype
- Sold or delivered
- not sold
- Where it is sold or used
- Tokyo Institute of Technology (Shigeo Hirose lab), Japan
- Customers and pilots
- None
Sources
Figures come from public sources. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use