Virginia Tech TREC Lab
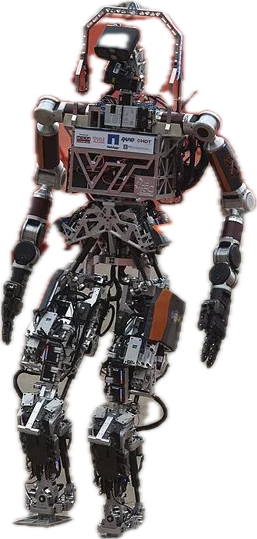
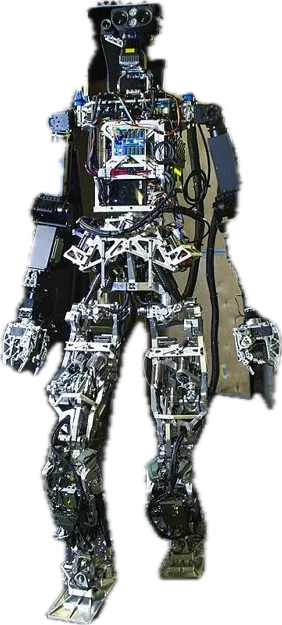
Virginia Tech robotics lab, led by Alexander Leonessa and Brian Lattimer among others, that built the linearly actuated, force-controlled humanoids SAFFiR, THOR and ESCHER. It fielded Team VALOR at the 2015 DARPA Robotics Challenge Finals.
- Robot models in the atlas
- 22 humanoids
- First robot
- 2014Latest 2015
- Headquarters
- BlacksburgUnited States
- Is it still sold?No longer soldEvery robot is retired or discontinued
- Who uses it?1 robot model in useTested aboard USS Shadwell in November 2014.
- What is new?2015-06ESCHER competes at DRC Finals
Robots
2 robot models shown in public, from 2014 to 2015. Newest first. Open one for its full profile.
What is inside
Chips and parts suppliers named for Virginia Tech TREC Lab's robots by the maker or reputable press.
Parts suppliers
Who uses it
Customers and deployments reported for Virginia Tech TREC Lab's robots. Each robot's page links its sources.
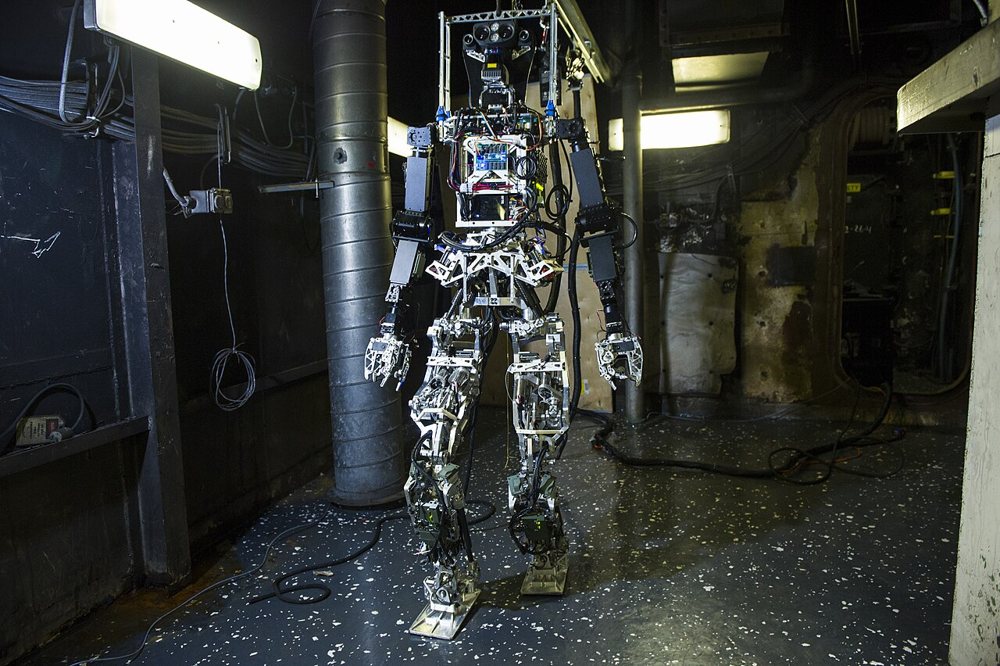 THOR / SAFFiR2014 · Retired
Tested aboard USS Shadwell in November 2014.
What is new
The latest stories about Virginia Tech TREC Lab's robots, newest first.
- ESCHER competes at DRC Finals Team VALOR / Journal of Field Robotics · ESCHER
- Spectrum profiles Virginia Tech's disaster robots IEEE Spectrum · THOR / SAFFiR
- SAFFiR fights fire aboard USS Shadwell Fire Engineering · THOR / SAFFiR
The company
What it says about itself and what the sources record.
- Headquarters
- Blacksburg, United States
- Focus
- Compliant humanoids driven by linear series elastic actuators for shipboard firefighting and disaster response
- Funding
- US Office of Naval Research (SAFFiR); DARPA Robotics Challenge (Team VALOR)
- Partners
- US Office of Naval Research (USS Shadwell tests, 2014)
Similar makers
Other makers of humanoids, starting with those in United States.
Sources
5 sources behind this page.
- Virginia Tech Innovative Design and Development of PANDORA: Advancing Humanoid Robotics Through Additive Manufacturing
- Fire Engineering Navy Unveils Firefighting Robot Prototype
- University of Technology Sydney OPUS Team VALOR's ESCHER: a novel electromechanical biped for the DARPA Robotics Challenge (Knabe et al., Springer STAR vol. 121, 2018)
- Virginia Tech VTechWorks Series Elasticity in Linearly Actuated Humanoids (V. Orekhov, PhD dissertation, 2015)
- DARPA DARPA Robotics Challenge (DRC)
Statistics only, not advice. No affiliation, sponsorship or endorsement. How we work · Terms