AgileX Robotics · working robot
Cobot Magic
Mobile ALOHA
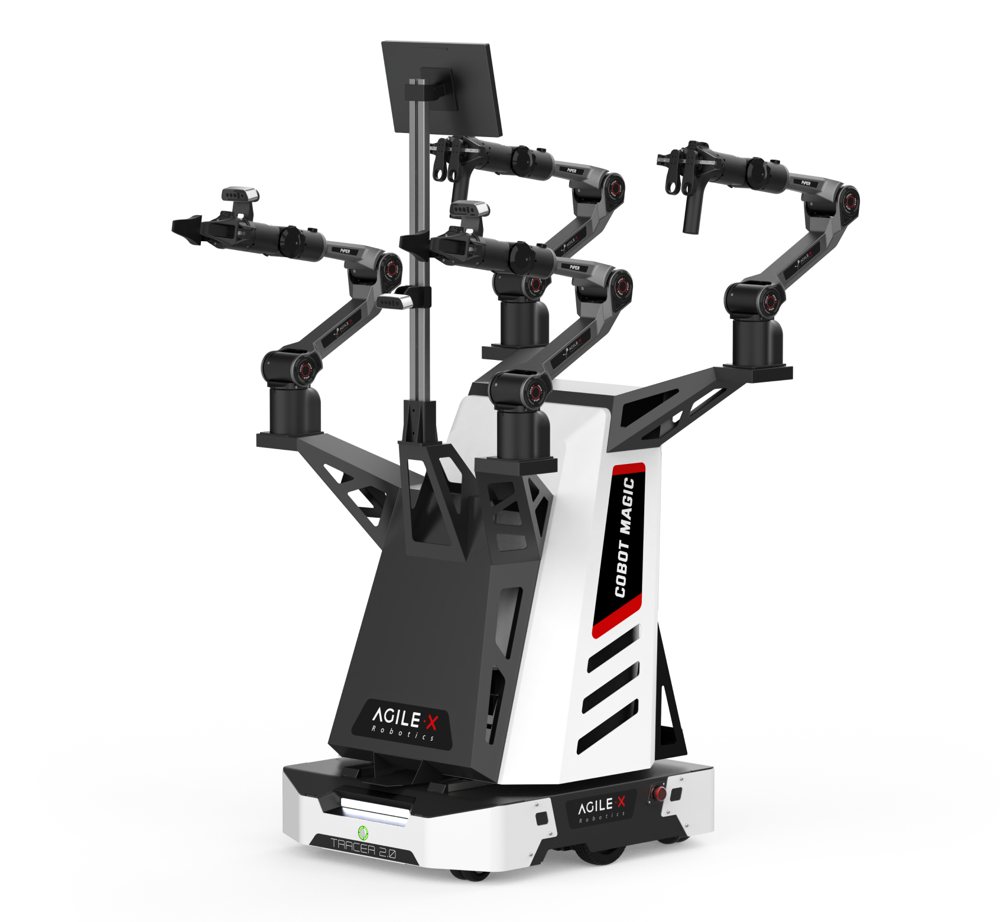
A wheeled base (AgileX's Tracer) carrying two robot arms plus a pair of leader arms that a person moves to teach it, with wrist and top cameras. Labs use it to record demonstrations and train robot-learning models.
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
A commercial version of Stanford's Mobile ALOHA design, which made two-armed mobile robot learning affordable for labs.
Real-world use
Sold to universities, research labs and industry teams for robot-learning data collection
Timeline
- Released
- Not yet
Maker
AgileX RoboticsCompany · founded 2016 · Shenzhen, ChinaPublic attention
How much public attention Cobot Magic (Mobile ALOHA) gets, from open data.
- No Wikipedia article of its own yet
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Wheeled base
- How it runs
- Remote-controlled. A person moves the leader arms to drive its arms directly so the lab can record demonstrations; learned policies can then run it on its own in experiments.
- Actuators & motors
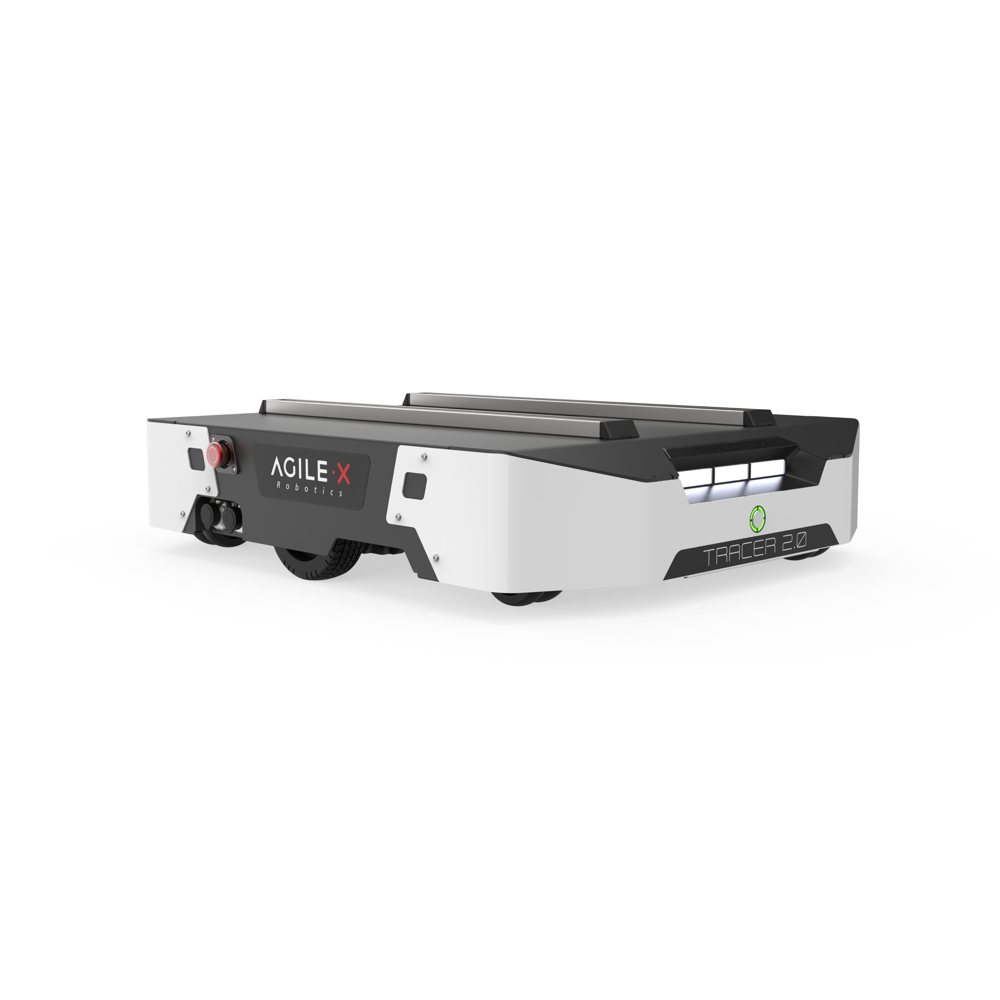
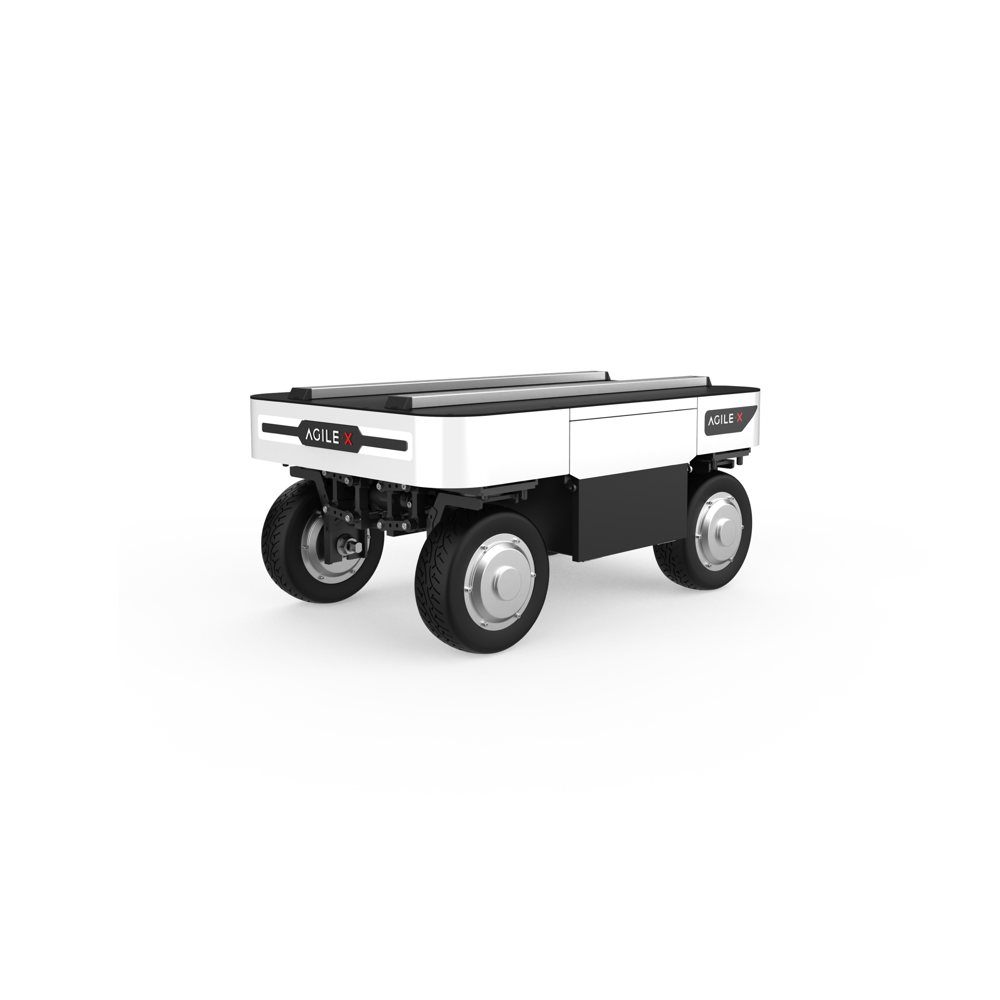
- Differential-drive AgileX Tracer wheeled base
- Hands
- Four robot arms: two follower arms with grippers that do the work and two leader (teaching) arms that a person moves to teleoperate them
- Sensors & vision
- Two wrist cameras and one top camera (depth camera)
- Compute
- Industrial PC on board (AgileX says more powerful than the original Mobile ALOHA build)
- AI & software
- Runs the open-source Stanford Mobile ALOHA code (teleoperation, data collection and ACT imitation learning) on ROS; AgileX also supports VLA and world-model training workflows
- Other details
- Commercial build of the Mobile ALOHA whole-body teleoperation system created at Stanford by Zipeng Fu, Tony Z. Zhao and Chelsea Finn.
Lineage
Every AgileX Robotics machine in order.
Watch Cobot Magic (Mobile ALOHA)
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Where it is sold or used
- AgileX Robotics, Shenzhen, China
- Customers and pilots
- Sold to universities, research labs and industry teams for robot-learning data collection
Sources
Figures come from the maker. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use