Jinki Ittai (Man-Machine Synergy Effectors) · industrial humanoid
Ichi-rei-shiki Jinki ver.1.0
一零式人機 ver.1.0
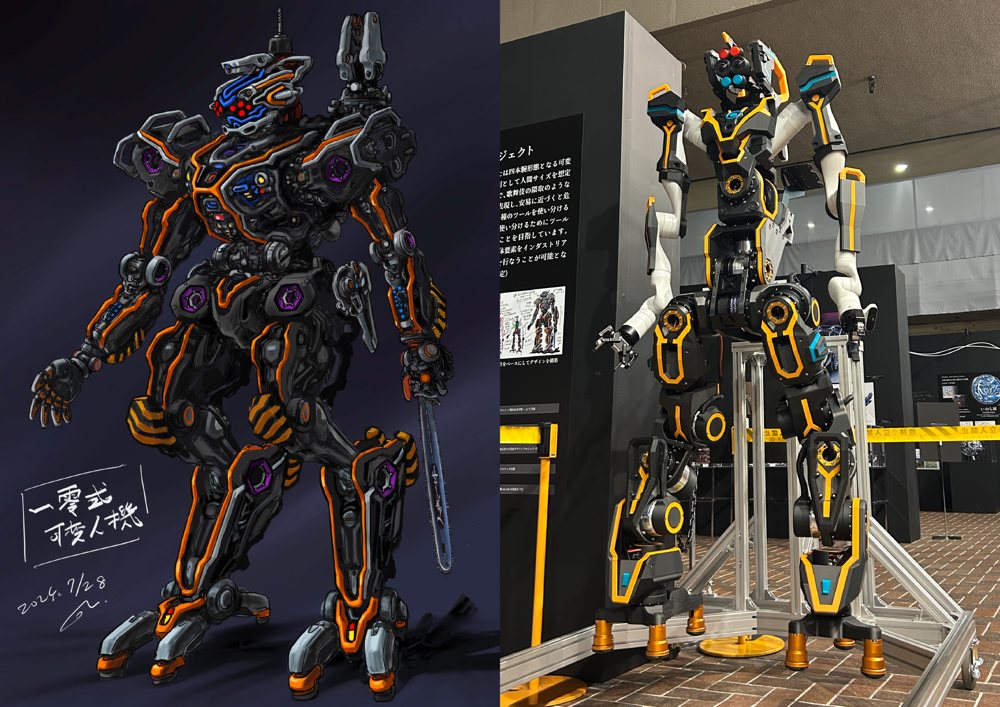
A life-size, human-operated humanoid prototype aimed at high-voltage power work at height: the concept walks on legs on the ground and works with four arms when carried in the bucket of an aerial work vehicle. It is the mechanism meant to sit inside the 'humanoid heavy machine' styled by anime designer Shoji Kawamori, and was shown with its exterior at Japan IT Week in April 2026.
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: factory work. Five more quick questions.
Why it matters
A prototype humanoid from Jinki Ittai (Man-Machine Synergy Effectors).
Real-world use
None named; Advantech collaboration on control computing (2026)
Maker
Jinki Ittai (Man-Machine Synergy Effectors)Company · JapanWhat it has been shown doing
We checked public videos and press for Ichi-rei-shiki Jinki ver.1.0 (一零式人機 ver.1.0) and found no clear demo of the skills we track yet.
Public attention
How much public attention Ichi-rei-shiki Jinki ver.1.0 (一零式人機 ver.1.0) gets, from open data.
- No Wikipedia article of its own yet
- 2 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs
- Actuators & motors
- Upper body currently uses off-the-shelf hardware and the lower body uses outside actuators; Jinki Ittai wants fully in-house actuators and structure later. The company is also promoting its own compound-planetary 'Jinki Rensei' reducer (reduction ratios up to about 10,000:1).
- Hands
- Concept calls for a standardised wrist interface and plug-and-play tool changer (grippers, power drivers, special tools) rather than a fixed hand; a tool rack sits on the back.
- AI & software
- Human-operated ('jinki') robot using Jinki Ittai's power-amplifying bilateral force-control teleoperation; force data handled at around 4,000 samples per second on industrial PCs in its Advantech tie-up.
- Other details
- Mounts at the waist to the tip of an aerial-work-vehicle boom and can work with two arms and two legs or four limbs; on the ground it walks. Target is remote high-voltage line work now done with insulated sticks. Exterior styled by anime designer Shoji Kawamori.
Named suppliers:Advantech
From the maker
Ichi-rei-shiki Jinki ver.1.0 (一零式人機 ver.1.0) is the only humanoid from Jinki Ittai (Man-Machine Synergy Effectors) in the atlas.
Watch Ichi-rei-shiki Jinki ver.1.0 (一零式人機 ver.1.0)
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Prototype (shown bare at iREX 2025, with exterior at Japan IT Week Spring 2026)
- Sold or delivered
- Not sold
- Where it is sold or used
- Japan
- Customers and pilots
- None named; Advantech collaboration on control computing (2026)
News
The latest 2, newest first. Summaries are ours; tap through for the original.
- Ichi-rei-shiki Jinki shown with exterior at Advantech booth
Static display at Japan IT Week Spring 2026 as Jinki Ittai and Advantech announced work on standard control PCs.
Kazumichi Moriyama (note) - Life-size prototype debuts at iREX 2025
MONOist reports the prototype that will sit inside the Kawamori-styled humanoid heavy machine, shown at Jinki Ittai's 10-partner booth.
MONOist
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | Ichi-rei-shiki Jinki ver.1.0 (一零式人機 ver.1.0)Jinki Ittai (Man-Machine Synergy Effectors) | 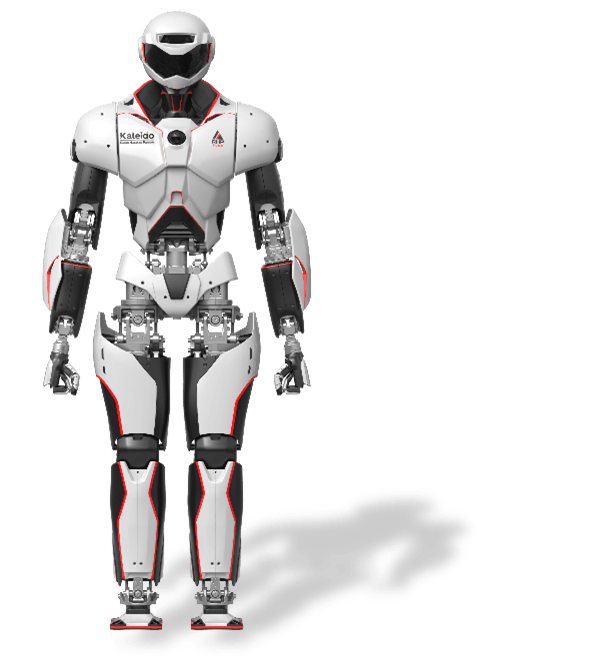 Kaleido 9 (RHP Kaleido)Kawasaki Heavy IndustriesSame job: industrial · Both walk · Both in development | 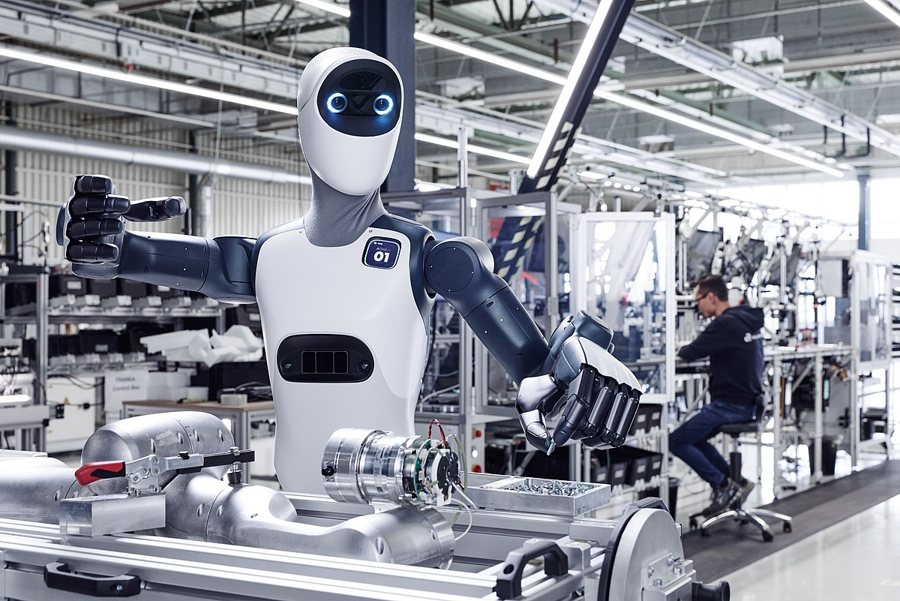 Agile ONEAgile RobotsSame job: industrial · Both walk · Both in development | 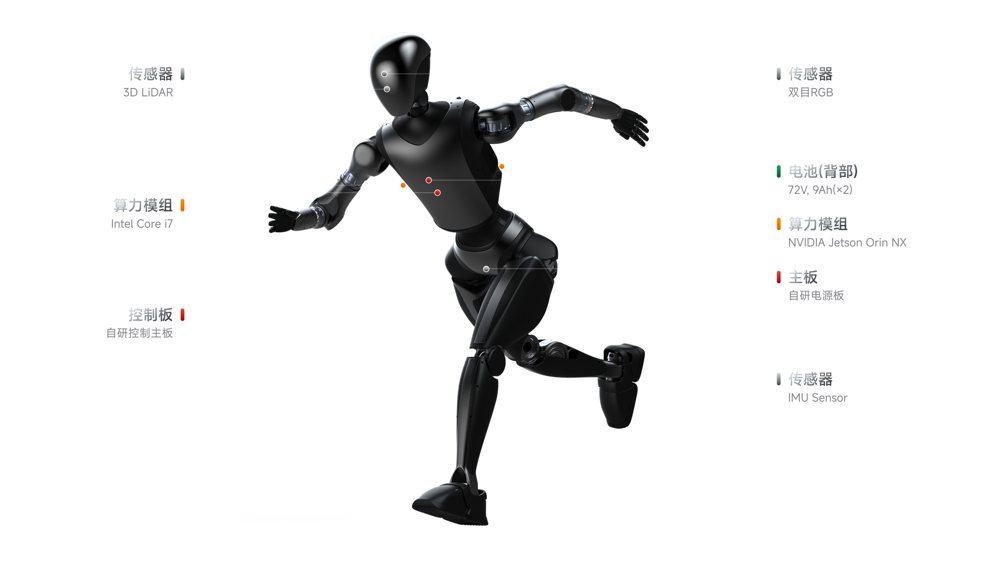 PHYBOT M1PHYBOTSame job: industrial · Both walk · Both in development |
|---|---|---|---|---|
| First shown | 2025-12-03 | 2025-12-03 | 2025-11-19 | 2025-11-21 |
| Status | Prototype | Prototype | Prototype | Prototype |
| Height | — | 190 cm | 174 cm | 172 cm |
| Weight | — | 99 kg | 69 kg | — |
| Joints | — | — | — | 32 |
| Speed | — | 5 km/h | 7.2 km/h | — |
| Payload | — | 30 kg | 20 kg | 20 kg |
| Battery | — | 3 h | — | 2 h |
| Price | — | — | — | — |
Sources
Figures come from public sources. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use