Microsoft (Kinect)Cameras and depth sensing · United States
Supplier · cameras and depth sensing
Microsoft (Kinect)
Microsoft's Kinect depth cameras were a staple of research-robot perception; the Azure Kinect DK documentation is now archived. No humanoid supply relationship was confirmed in the sources reviewed.
- Category
- Cameras and depth sensing
- Country
- United States
- Founded
- 2010
- Reported customers
- —Not published
- Robots
- 11Name it in their parts
- Listed
- —Not published
What it makes
From the company's own description and the sources below.
- Makes
- Kinect and Azure Kinect RGB-D depth cameras, widely used on research robots for perception and body tracking.
- Parts
- Depth camera
- Tier
- Components
- Founded
- 2010
- Products
- Kinect for Xbox 360, Kinect v2, Azure Kinect DK, Azure Kinect Sensor SDK
Named in robots' parts lists
Quotes are from each robot's parts profile, which links its sources.
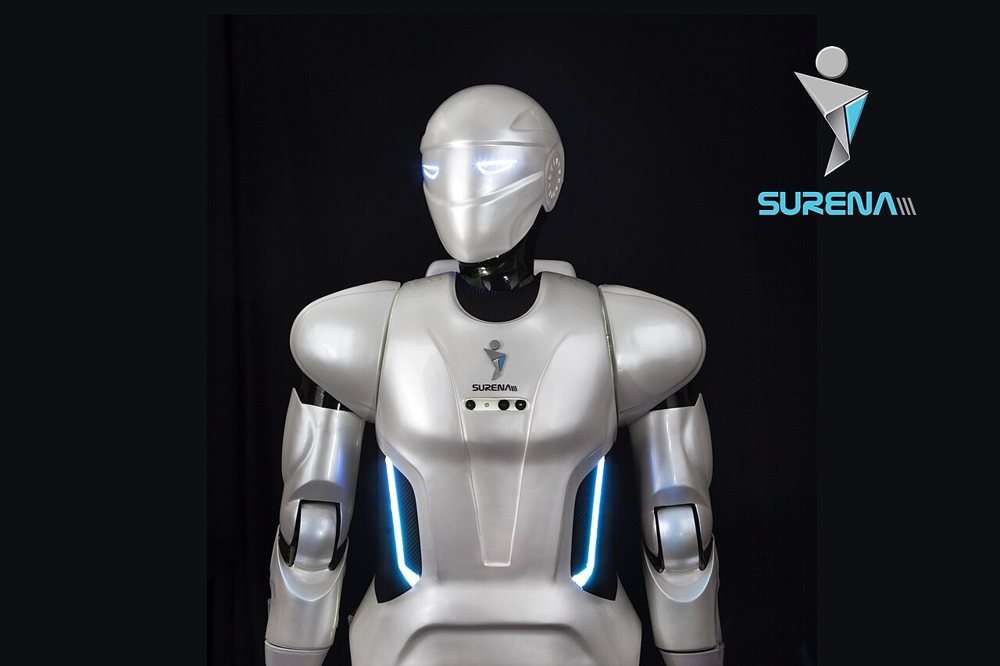 Surena IIIUniversity of Tehran, Center for Advanced Systems and Technologies (CAST) · 2015Retired
“Kinect-based 3D vision module, encoders in all joints, six-axis force/torque sensors in the ankles, IMU in the torso, microphones for recognising some set Persian sentences.”
- No public photo yetWe only show photos we're allowed to useFLASHWroclaw University of Technology (Jan Kedzierski) · 2012Discontinued
“Hokuyo URG laser range finder, Analog Devices inertial system, Microsoft Kinect, Logitech QuickCam Sphere camera.”
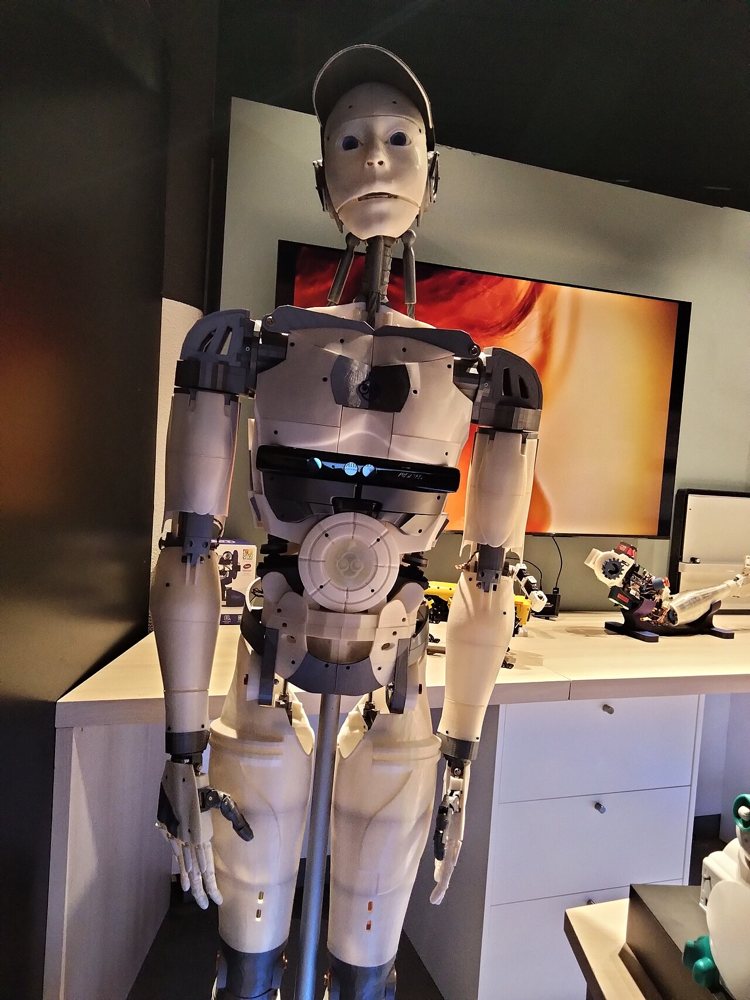 InMoovInMoov (Gael Langevin) · 2012Research
“Kinect for 3D sensing;”
- No public photo yetWe only show photos we're allowed to useKIBOKorea Institute of Science and Technology (KIST) · 2011Research
“Microsoft Kinect;”
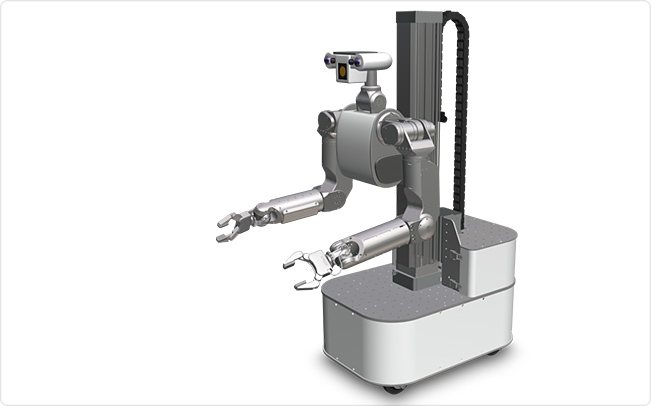 M1 Mobile ManipulatorMeka Robotics · 2011Discontinued
“Pan-tilt head with a Microsoft Kinect 3D camera and a 5-megapixel Ethernet camera;”
- No public photo yetWe only show photos we're allowed to useSmartPal VIIYaskawa Electric · 2011Retired
“A remote operator's arm motions, captured by a Microsoft Kinect, are mapped by Yaskawa's software onto the robot's hand, waist and trolley motion.”
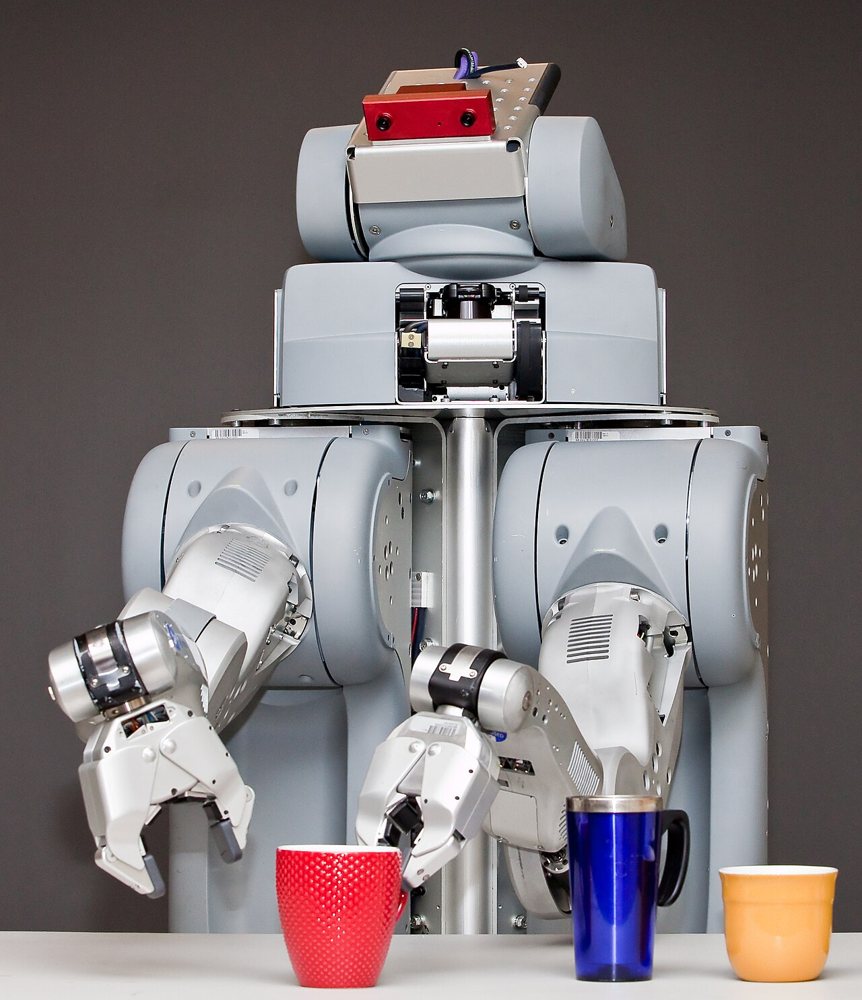 PR2Willow Garage · 2010Discontinued
“Wide- and narrow-angle head stereo cameras, 5 MP camera, forearm Ethernet cameras, Microsoft Kinect, Hokuyo UTM-30LX lasers on the tilting torso mount and base, Microstrain 3DM-GX2 IMU and arm accelerometers.”
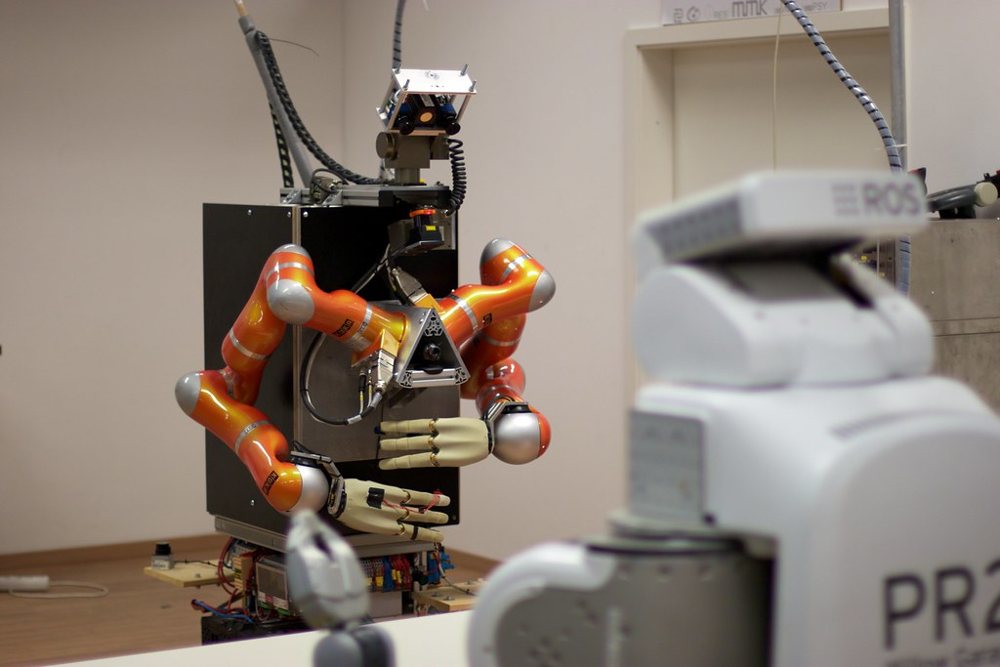 RosieTechnical University of Munich · 2009Retired
“Two high-resolution cameras, a thermal camera, three laser scanners, fingertip mini cameras, Microsoft Kinect.”
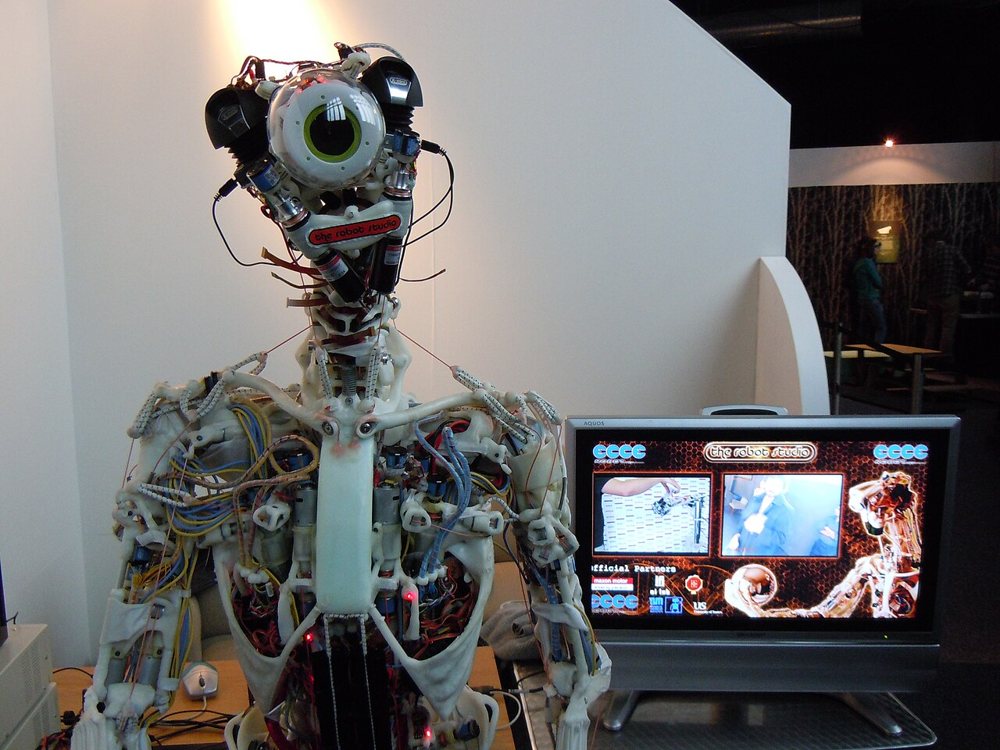 ECCE (ECCEROBOT)The Robot Studio and the EU ECCEROBOT project · 2009Retired
“Camera (a Kinect 3D sensor served as eyes on later versions), microphone, muscle-length and tension sensors, motor current and position sensors.”
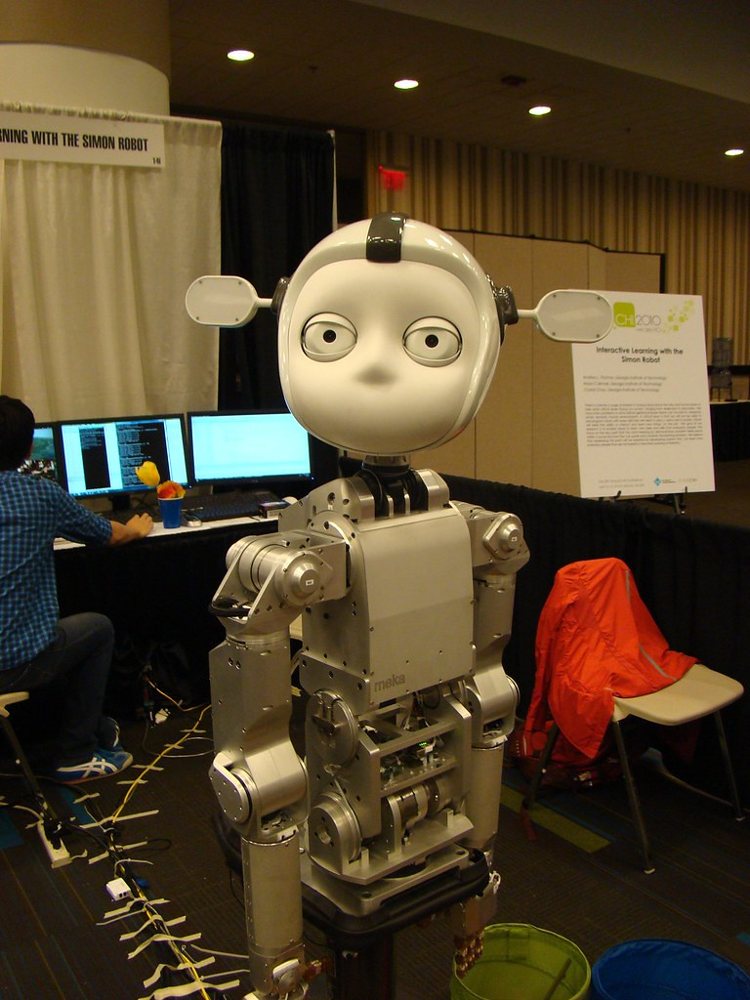 SimonGeorgia Institute of Technology (Socially Intelligent Machines Lab) · 2008Retired
“Camera eyes, Microsoft Kinect (later addition), microphone.”
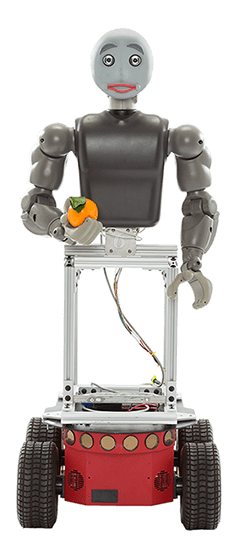 BanditUSC Interaction Lab and BlueSky Robotics · 2006Research
“a Microsoft Kinect and custom IMUs depending on the study.”
Sources
Where each fact on this page comes from.
Statistics only, not advice. No affiliation, sponsorship or endorsement. How we work · Terms