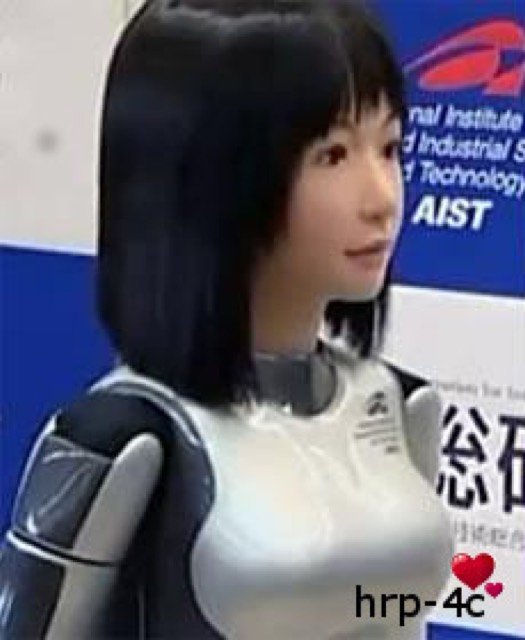
National Institute of Advanced Industrial Science and Technology (AIST) · entertainment humanoid
HRP-4C
A 'cybernetic human' with body proportions set to the average young Japanese woman, motion-captured human-like walking, speech recognition and singing.
- Price
- —Not published
- Height
- 158 cmTaller than 38%
- Weight
- 43 kgHeavier than 28%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
First humanoid robot to walk a fashion-show catwalk (Japan Fashion Week, March 2009), with a realistic female face.
Real-world use
Appeared at Japan Fashion Week 2009 and CEATEC 2009, and danced with human performers in 2010.
Timeline
- Released
- Not yet
Maker
National Institute of Advanced Industrial Science and Technology (AIST)Government lab · founded 2001 · Tokyo, JapanGovernment-funded (METI-overseen); HRP-5P work funded by NEDO and JSPS
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
HRP-4C is taller than 38% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
HRP-4C is heavier than 28% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
HRP-4C has more joints than 74% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Not published by the maker: speed, payload, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- 1,803 views of its Wikipedia article in the last 90 days (HRP-4C)
- 4 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 42 joints
- Actuators & motors
- Eight actuators in the head enable facial expressions (IEEE Spectrum, 2010).
- Hands
- 2 DoF per hand with silicone skin.
- Sensors & vision
- Speech recognition enables responses to human speech (AIST, 2009).
- Compute
- Intel Pentium M 1.6 GHz with wireless networking; a computer in the head runs speech recognition (AIST).
- Battery & power
- 48 V nickel-metal hydride, included in the 43 kg weight (AIST).
- Materials & build
- Silicone rubber skin on face and hands, hard plastic exterior, metal and plastic frame.
- AI & software
- Real-time Linux, RT middleware and OpenHRP3 simulator; motion-captured human movements guide walking (AIST, 2009).
- Other details
- Body dimensions set to the average young Japanese woman from a 1997-98 body database; uses Honda patents and HRP-2 technology (AIST).
Named suppliers:Intel
Lineage
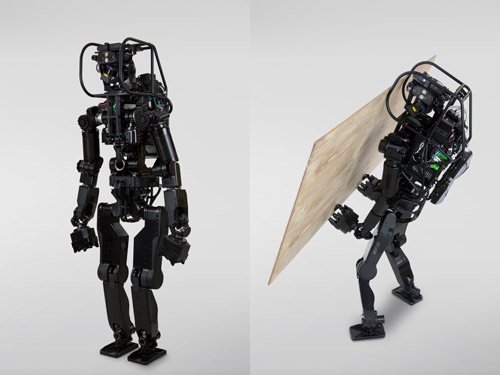
Every AIST humanoid in order.
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Research unit; count not published
- Where it is sold or used
- Japan
News
The latest 4, newest first. Summaries are ours; tap through for the original.
- HRP-4C walking upgraded
Toe support improved HRP-4C walking.
TechCrunch - Development of Integrated Software to Generate Humanoid Robot Motion Easily
AIST used Choreonoid to generate HRP-4C dance motions for Digital Content Expo 2010.
AIST - Walks the Japan Fashion Week catwalk
HRP-4C appeared at Japan Fashion Week in Tokyo a week after its unveiling.
AIST - AIST unveils the 'cybernetic human'
AIST issued its press release and first public demonstration.
AIST
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | HRP-4CAIST | 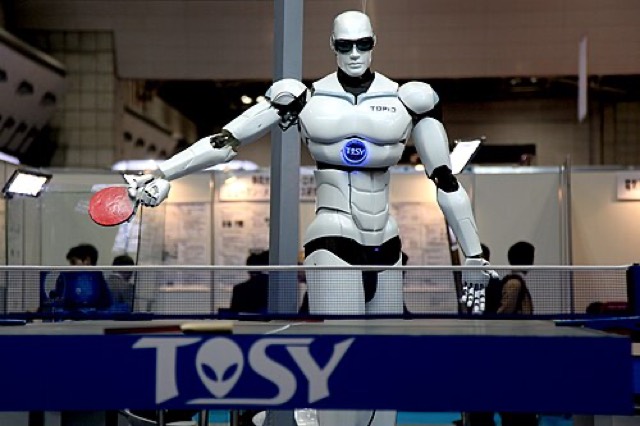 TOPIOTOSY RoboticsSame job: entertainment · Both walk · Both past robots · Similar size | 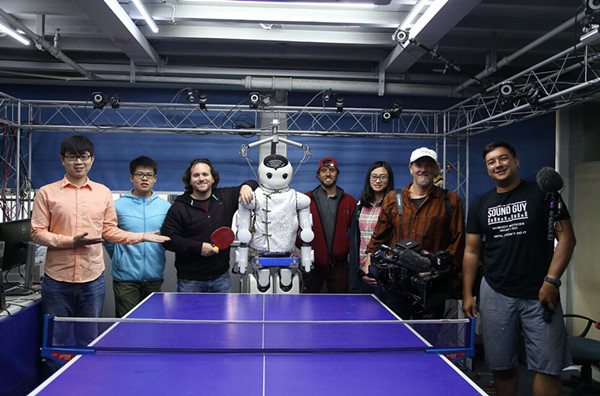 Wu and KongZhejiang University (Xiong Rong's team)Same job: entertainment · Both walk · Both past robots · Similar size | 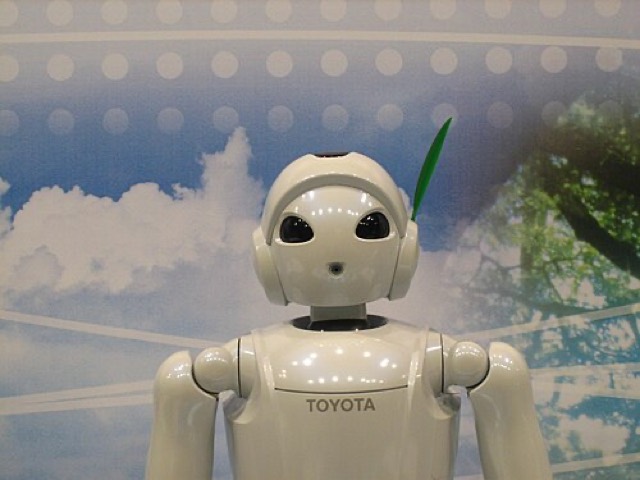 Toyota Partner Robot (violin-playing)Toyota Motor CorporationSame job: entertainment · Both walk · Both past robots · Similar size |
|---|---|---|---|---|
| First shown | 2009-03-16 | 2007-11-28 | 2011-10 | 2007-12-06 |
| Status | Retired | Retired | Retired | Retired |
| Height | 158 cm | 188 cm | 160 cm | 152 cm |
| Weight | 43 kg | 120 kg | 55 kg | 56 kg |
| Joints | 42 | 39 | 30 | — |
| Speed | — | — | — | — |
| Payload | — | — | — | — |
| Battery | — | — | — | — |
| Price | — | — | — | — |
Sources
Figures come from the maker. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use