UC Berkeley Biomimetic Millisystems Lab · legged machine
Salto / Salto-1P
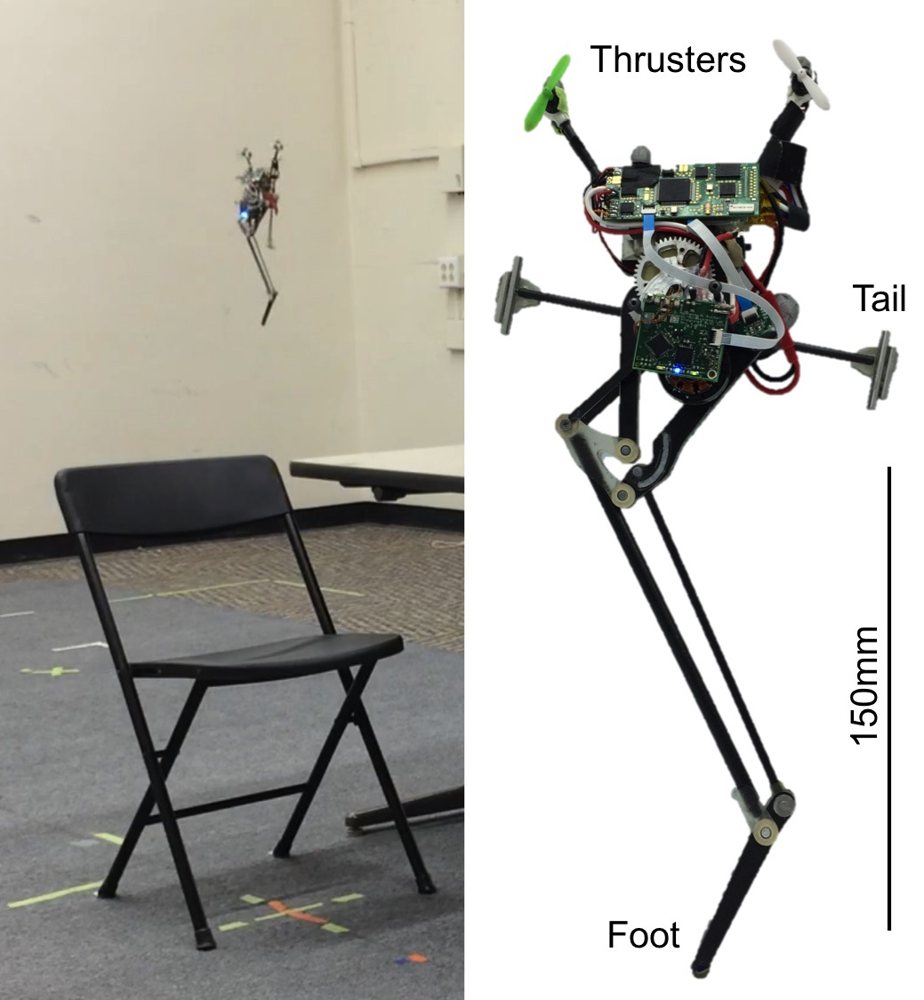
A 118-gram monopod that jumps up to 1.25 m and does most of its control while airborne. Salto-1P is the later, untethered version.
- Price
- —Not published
- Height
- —Not published
- Weight
- 0.1 kgHeavier than 4%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
A one-legged jumping robot able to bounce off walls and chain jumps, steering itself in mid-air with a tail and thrusters.
Real-world use
No customers or deployments reported yet.
Timeline
- First shown
- 2016
- Released
- Not yet
Maker
UC Berkeley Biomimetic Millisystems LabUniversity lab · Berkeley, California, USAHow it stacks up
Against other legged & novel that publish the figure. Pick a measure.
Salto / Salto-1P is heavier than 4% of the 25 other legged & novel that publish a weight. Bars show the 7 closest in date.
Salto / Salto-1P has more joints than 6% of the 16 other legged & novel that publish a joints. Bars show the 7 closest in date.
Not published by the maker: height, speed, payload, battery, price.
Public attention
How much public attention Salto / Salto-1P gets, from open data.
- No Wikipedia article of its own yet
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 4 joints
- How it runs
- Assisted. Researchers steered its jumps with commands while it controlled its own balance and landing, at first using external motion capture.
- Actuators & motors
- Brushless DC motor (modified Scorpion S-1804) driving the leg through a latex series-elastic torsion spring and linkage; reaction-wheel tail; two propeller thrusters on Salto-1P
- Sensors & vision
- InvenSense MPU6000 IMU and magnetic encoders on leg, tail and motor
- Compute
- ImageProc 2.5 board with a dsPIC33 microcontroller; ground station runs ROS or Python
- Battery & power
- 14.8 V, 220 mAh lithium pack, about 12 minutes
- Materials & build
- Carbon-fibre honeycomb and tubes, cast polyurethane, aluminium gears, 3D-printed parts
- Other details
- 0.118 kg, 31 cm tall; jumps up to 1.25 m
Lineage
Every UC Berkeley Biomimetic Millisystems Lab (Justin Yim, Ronald Fearing) machine in order.
Watch Salto / Salto-1P
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Research robot
- Sold or delivered
- not sold
- Where it is sold or used
- UC Berkeley
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use