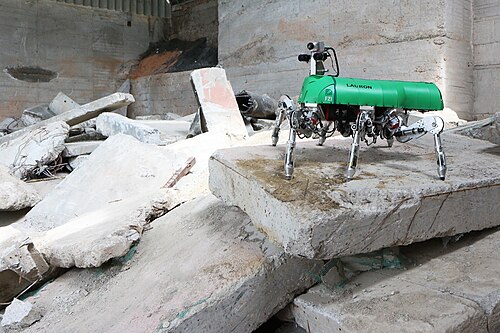
FZI Research Center for Information Technology · legged machine
LAURON V
The fifth generation of FZI's LAURON hexapods, with four joints per leg and a gripper. Height is 61 cm normally and 84 cm with legs fully extended.
- Price
- $200,000Cheaper than 14%
- Height
- 84 cmTaller than 36%
- Weight
- 43.5 kgHeavier than 52%
- Payload
- —Not published
- Speed
- 0.5 km/hFaster than 11%
- Battery
- 2 hRuns longer than 33%
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
A stick-insect-inspired hexapod able to run fully autonomous exploration missions using 3D mapping and path planning.
Real-world use
None (research)
Timeline
- First shown
- 2013
- Released
- Not yet
Maker
FZI Research Center for Information TechnologyGovernment lab · Karlsruhe, GermanyHow it stacks up
Against other legged & novel that publish the figure. Pick a measure.
LAURON V is taller than 36% of the 22 other legged & novel that publish a height. Bars show the 7 closest in date.
LAURON V is heavier than 52% of the 25 other legged & novel that publish a weight. Bars show the 7 closest in date.
LAURON V is faster than 11% of the 19 other legged & novel that publish a speed. Bars show the 7 closest in date.
LAURON V has more joints than 81% of the 16 other legged & novel that publish a joints. Bars show the 7 closest in date.
LAURON V runs longer than 33% of the 6 other legged & novel that publish a battery. Bars show the 6 closest in date.
LAURON V costs less than 14% of the 7 other legged & novel that publish a price. Bars show the 7 closest in date.
Not published by the maker: payload.
Public attention
How much public attention LAURON V gets, from open data.
- 299 views of its Wikipedia article in the last 90 days (LAURON)
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 28 joints
- How it runs
- Assisted. Its external control center could supply speed and gait commands while onboard behaviors coordinated its legs and adapted walking to unfamiliar terrain.
- Actuators & motors
- 28 motors: four joints per leg with Faulhaber brushed DC motors and planetary gearheads (66:1 and 159:1), chain and worm drives; brushless motors for gripper and laser scanner.
- Hands
- 1-DoF gripper on a front leg; legs also used for manipulation.
- Sensors & vision
- Two Asus Xtion Pro Live depth cameras, two Point Grey Firefly cameras, FLIR thermal camera, Velodyne HDL-32E or custom 3D laser scanner (Hokuyo UTM-30LX), Microstrain IMU, joint encoders and motor-current sensing.
- Compute
- Mini-ITX Intel Core i7 main computer, Intel NUC i7 vision computer, custom DSP/FPGA leg controllers, Arduino and Raspberry Pi helpers.
- Battery & power
- Two 24 V 8,000 mAh lithium-polymer packs, about 2 hours; hot-swappable.
- Materials & build
- Aerospace aluminium legs; POM, PE and 3D-printed PLA shell parts; brass worm gears.
- AI & software
- Ubuntu 14.04 with ROS Indigo for high-level control (PLEXNAV framework, OMPL, OpenCV, PCL, SMACH, 3D SLAM); MCA2 behaviour-based low-level control.
- Other details
- About 43.5 kg; 0.5 km/h. Leg design and gaits based on the stick insect. Earlier LAURONs date to 1994.
From the maker
LAURON V is the only machine from FZI Research Center for Information Technology in the atlas.
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- $200,000about EUR 150,000; USD converted at roughly 2013 rates
- How to get one
- No official buying page found
- Built
- Research robot
- Sold or delivered
- not sold; cost about €150,000
- Where it is sold or used
- FZI Research Center for Information Technology, Karlsruhe, Germany
- Customers and pilots
- None (research)
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use