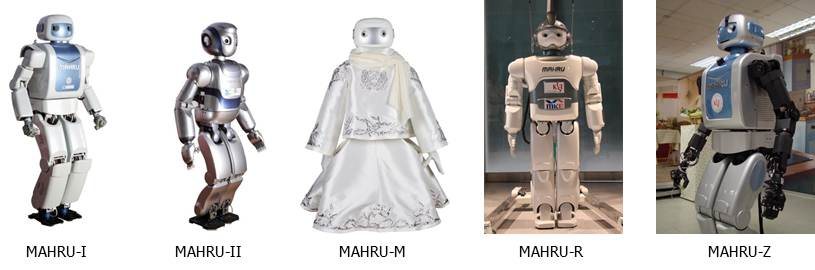
Korea Institute of Science and Technology · research humanoid
MAHRU
A full-size biped from KIST built to walk and do household tasks, either on its own or teleoperated in near real time by a person wearing a motion-capture suit. It could recognise faces, objects and places and walk around obstacles.
- Price
- —Not published
- Height
- 150 cmTaller than 34%
- Weight
- 67 kgHeavier than 58%
- Payload
- —Not published
- Speed
- 1.2 km/hFaster than 7%
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: help at home. Five more quick questions.
Why it matters
A retired humanoid from Korea Institute of Science and Technology (KIST).
Real-world use
No customers or deployments reported yet.
Timeline
- First shown
- 2005
- Released
- Not yet
Maker
Korea Institute of Science and TechnologyGovernment lab · founded 1966 · Seoul, South KoreaGovernment-funded public research institute
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
MAHRU is taller than 34% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
MAHRU is heavier than 58% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
MAHRU is faster than 7% of the 122 other humanoids that publish a speed. Bars show the 7 closest in date.
MAHRU has more joints than 61% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Not published by the maker: payload, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- No Wikipedia article of its own yet
- 4 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs · 35 joints
- Actuators & motors
- 37 DC servomotors; 37 DoF (7 per arm, 6 per leg, 4 per hand, 2 neck, 1 waist).
- Hands
- 4 DoF per hand; the later MAHRU-Z reportedly had six fingers.
- Sensors & vision
- Stereo camera, force-torque sensors, microphone and laser range finder; KIST's own spec list adds a gyro sensor.
- Compute
- On-board computer and joint controllers linked over IEEE 1394 or EtherCAT; designed as a network-based robot that draws on off-board servers for intelligence.
- Battery & power
- Lithium-polymer battery, about 3 hours of operation; KIST lists 48 V, 20 A.
- Materials & build
- 150 cm, 67 kg (KIST).
- AI & software
- Linux with the Xenomai real-time extension; face, object, gesture and place recognition; autonomous or teleoperated in near real time via an inertial motion-capture suit.
- Other details
- Paired with the orange sister robot AHRA; demonstrated household tasks such as making breakfast, plus dancing and taekwondo. Later versions included MAHRU-R, MAHRU-M and MAHRU-Z.
Lineage
Every Korea Institute of Science and Technology (KIST) humanoid in order.
Watch MAHRU
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- Several versions (MAHRU-1, -2/III, -R, -M, -Z); unit count not stated
- Sold or delivered
- Not sold; research robot
- Where it is sold or used
- KIST, Seoul, South Korea
News
The latest 4, newest first. Summaries are ours; tap through for the original.
- MAHRU-M mobile platform published
KIST researchers described MAHRU-M, a wheeled version with a dual-network control system, in Robotics and Autonomous Systems.
Crossref (Elsevier record) - S.Korean scientists develop walking robot maid
MAHRU-Z was reported with a rotating head, arms and legs, six fingers and three-dimensional vision for household chores.
AFP / Phys.org - Network-based MAHRU paper at IFAC 2008
KIST presented MAHRU as a network-based humanoid companion at the IFAC World Congress in Seoul.
Crossref (IFAC record) - Mahru III presented at Humanoids 2007
A paper on the biped Mahru III appeared at IEEE Humanoids 2007, with co-authors including Samsung researchers.
Crossref (IEEE record)
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. Few robots match closely, so these are the nearest matches. How we choose
| Measure | MAHRUKorea Institute of Science and Technology (KIST) | 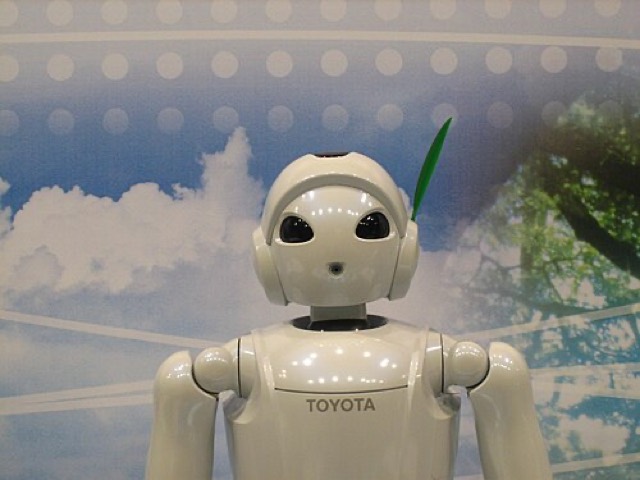 Toyota Partner Robot (violin-playing)Toyota Motor CorporationSame job: home · Both walk · Both past robots · Similar size | 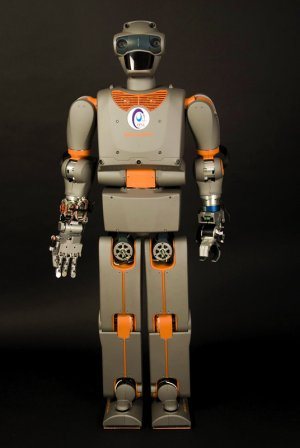 REEM-BPAL RoboticsSame job: home · Both walk · Both past robots |
|---|---|---|---|
| First shown | 2005 | 2007-12-06 | 2008-06 |
| Status | Retired | Retired | Retired |
| Height | 150 cm | 152 cm | 147 cm |
| Weight | 67 kg | 56 kg | 64 kg |
| Joints | 35 | — | 41 |
| Speed | 1.2 km/h | — | 1.5 km/h |
| Payload | — | — | 12 kg |
| Battery | — | — | 2 h |
| Price | — | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use