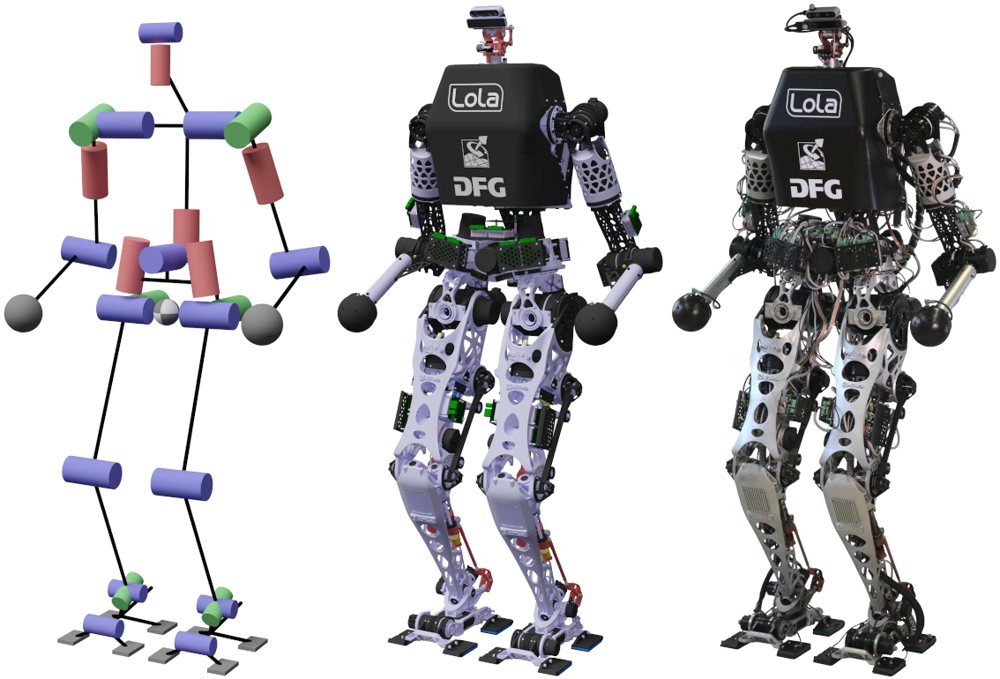
Technical University of Munich (TUM) · research humanoid
LOLA
A full-size, lightweight biped for fast walking research that copes with unexpected uneven and soft ground and can brace with its arms.
- Price
- —Not published
- Height
- 180 cmTaller than 86%
- Weight
- 55 kgHeavier than 38%
- Payload
- —Not published
- Speed
- 3.3 km/hFaster than 28%
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
A research humanoid from Technical University of Munich.
Real-world use
No customers or deployments reported yet.
Timeline
- First shown
- 2010
- Released
- Not yet
Maker
Technical University of Munich (TUM)University lab · founded 1868 · Munich, GermanyPublic university (budget about EUR 2.17 billion in 2024, including the university hospital)
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
LOLA is taller than 86% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
LOLA is heavier than 38% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
LOLA is faster than 28% of the 122 other humanoids that publish a speed. Bars show the 7 closest in date.
LOLA has more joints than 30% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Not published by the maker: payload, battery, price.
What it has been shown doing
1 of 14 skills we track, each from a public video or report. Demos can be staged or remote-controlled; we say so when the source does.
- Rough groundwalks over uneven terrain (6 cm height variation) and unexpected obstacles with vision off, using force control (2020 paper; date approximate) · Jan 2020 · mec.ed.tum.de
Not shown yet:SortAssembleFoldKitchenToolsFineStairsGet upRunJumpCarryOn siteAutonomous
Public attention
How much public attention LOLA gets, from open data.
- No Wikipedia article of its own yet
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Hands
- none
- Movement
- Walks on legs · 25 joints
- Actuators & motors
- Custom brushless DC motors with harmonic drive gears; parallel-kinematic legs with a roller-screw knee giving up to 380 Nm. 26 degrees of freedom: head 2, each arm 4, pelvis 2, each leg 7.
- Sensors & vision
- iMAR iVRU-FC-C167 IMU in the torso, custom force-torque sensors in the feet, Schunk FTE-Axia80 force-torque sensors at the hands, Intel RealSense T265 and D435 cameras in the head, motor-side and link-side joint encoders.
- Compute
- Two mini-ITX industrial boards, each with an Intel Core i7-8700 and 32 GB RAM, an NVIDIA Quadro P2000 GPU, an ELMO servo controller per joint and an EtherCAT bus.
- Battery & power
- External supply feeding 24 V and 80 V circuits.
- Materials & build
- Aluminium, 3D-printed titanium and stainless steel.
- AI & software
- QNX Neutrino RTOS 7.0 for control, Ubuntu 20.04 for computer vision, and TUM's broccoli library.
- Other details
- 176 cm, 68 kg; walks at up to 3.38 km/h.
Named suppliers:NVIDIAIntelIntel RealSenseHarmonic DriveQNXSCHUNK
Lineage
Every Technical University of Munich humanoid in order.
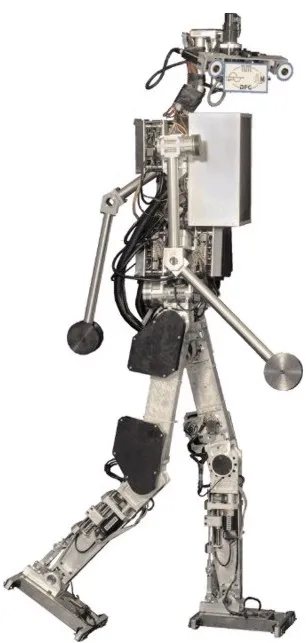
Watch LOLA
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- One research robot.
- Sold or delivered
- Never sold.
- Where it is sold or used
- Germany
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | LOLATechnical University of Munich | 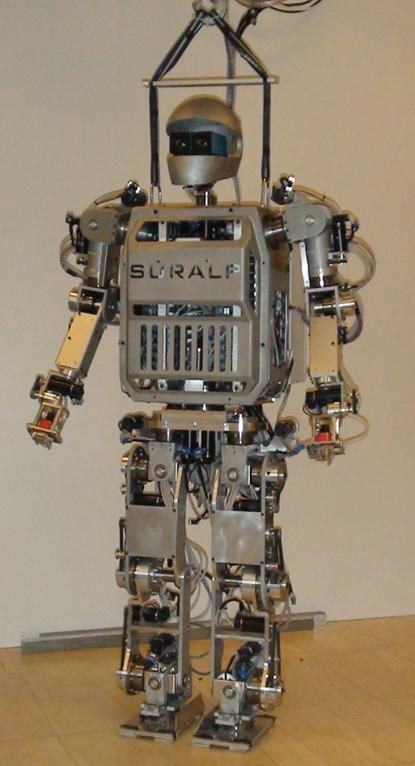 SURALPSabanci University (Kemalettin Erbatur's mechatronics team)Same job: research · Both walk · Both research platforms · Similar size | 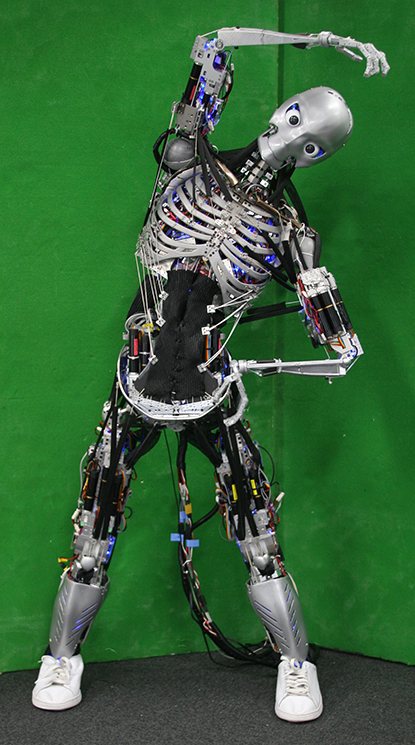 KenshiroUniversity of Tokyo JSK Lab (Masayuki Inaba, Kei Okada)Same job: research · Both walk · Both research platforms · Similar size | 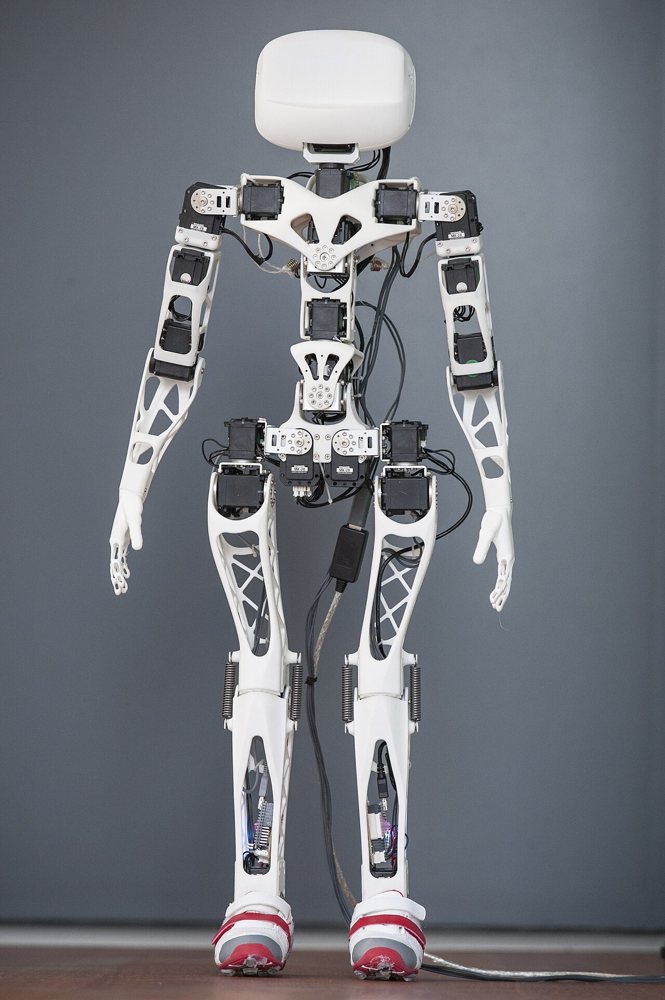 Poppy HumanoidInria Flowers Laboratory (now Poppy Station)Same job: research · Both walk · Both research platforms |
|---|---|---|---|---|
| First shown | 2010 | 2010-10-13 | 2012-11 | 2012 |
| Status | Research | Research | Research | Research |
| Height | 180 cm | 164 cm | 158 cm | — |
| Weight | 55 kg | 114 kg | 50 kg | — |
| Joints | 25 | 29 | 64 | — |
| Speed | 3.3 km/h | — | — | — |
| Payload | — | — | — | — |
| Battery | — | — | — | — |
| Price | — | $1,000,000 | — | $8,000 |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use