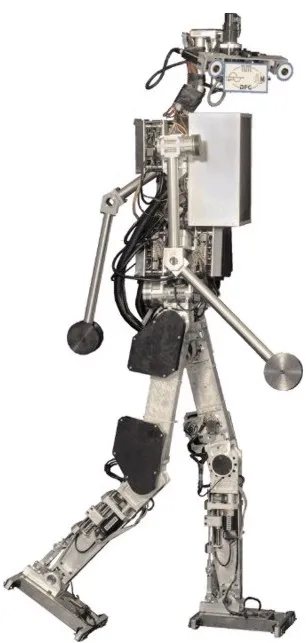
Technical University of Munich (TUM) · research humanoid
JOHNNIE
A 1.80 m, about 49 kg biped with 17 driven joints (six per leg, one in the upper body and two small arms that swing to cancel body rotation). It carried its own sensors and computer but took power by cable, walked on even and uneven ground at up to 2.2 km/h and was shown at the Hannover Fair in 2003 with camera-based vision guidance.
- Price
- —Not published
- Height
- 180 cmTaller than 86%
- Weight
- 49 kgHeavier than 33%
- Payload
- —Not published
- Speed
- 2.2 km/hFaster than 18%
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
One of Germany's first autonomous full-size biped walking robots, built under the German Research Foundation's Autonomous Walking programme; predecessor of TUM's LOLA.
Real-world use
No customers or deployments reported yet.
Timeline
- Released
- Not yet
Maker
Technical University of Munich (TUM)University lab · founded 1868 · Munich, GermanyPublic university (budget about EUR 2.17 billion in 2024, including the university hospital)
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
JOHNNIE is taller than 86% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
JOHNNIE is heavier than 33% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
JOHNNIE is faster than 18% of the 122 other humanoids that publish a speed. Bars show the 7 closest in date.
JOHNNIE has more joints than 3% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Not published by the maker: payload, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- No Wikipedia article of its own yet
- No recent press stories listed yet
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
No component details published yet.
- Hands
- none
- Movement
- Walks on legs · 17 joints
Lineage
Every Technical University of Munich (Institute of Applied Mechanics) humanoid in order.
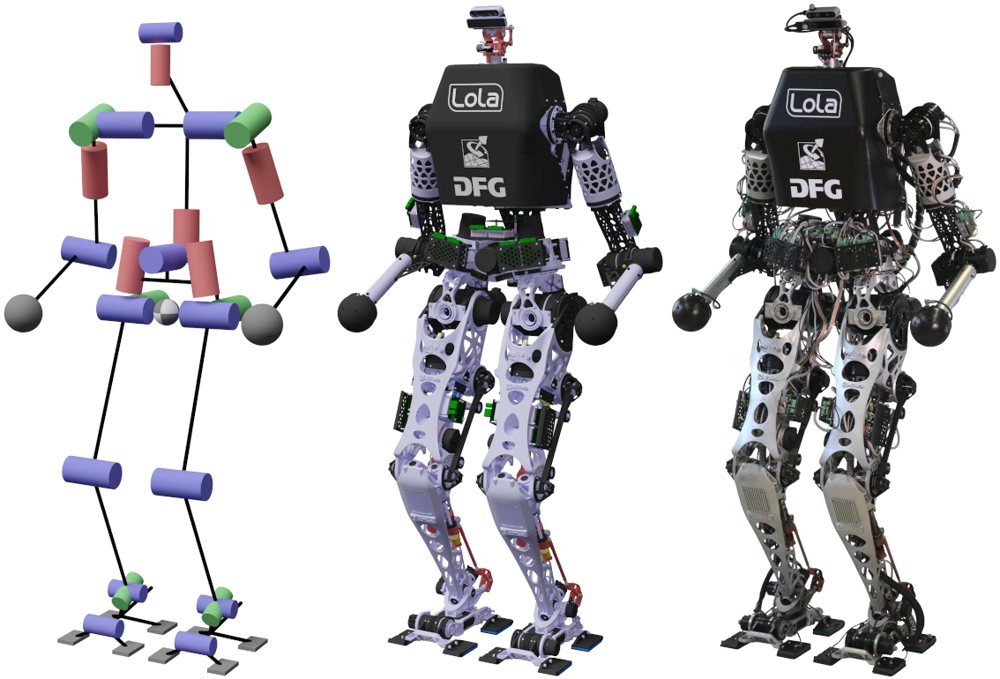
Made, sold and where
No production or sales figures published yet.
- Price
- Not published
- How to get one
- No official buying page found
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | JOHNNIETechnical University of Munich (Institute of Applied Mechanics) | No public photo yetWe only show photos we're allowed to useBHR-2 (Huitong)Beijing Institute of TechnologySame job: research · Both walk · Both past robots · Similar size |  CB (Computational Brain) / CB-iATR Computational Neuroscience Laboratories and JST ICORP, hardware by SARCOSSame job: research · Both walk · Both past robots · Similar size | 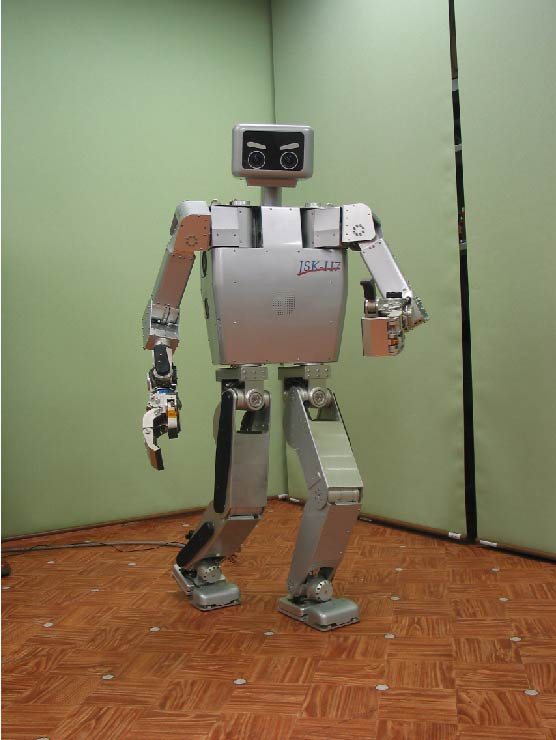 H7University of Tokyo JSK Lab (Inoue-Inaba Lab), built with Kawada IndustriesSame job: research · Both walk · Both past robots |
|---|---|---|---|---|
| First shown | 2003-04 | 2005-09-18 | 2006 | 2001 |
| Status | Retired | Retired | Retired | Retired |
| Height | 180 cm | 160 cm | 155 cm | — |
| Weight | 49 kg | 63 kg | 85 kg | — |
| Joints | 17 | 32 | 51 | — |
| Speed | 2.2 km/h | — | — | — |
| Payload | — | — | — | — |
| Battery | — | — | — | — |
| Price | — | — | — | — |
Sources
Figures come from the maker. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use