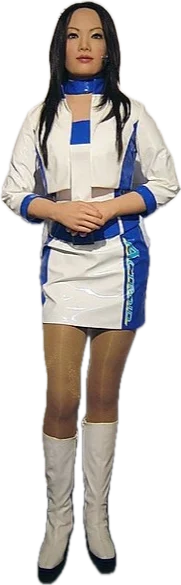
Osaka University · social humanoid
Actroid
Repliee Q1
A life-size female android whose upper body moved through pneumatic actuators to make natural gestures and facial expressions; lower-body motion was limited. Later variants were DER, DER2, DER3 and Actroid-F (2011).
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: greet and guide customers. Five more quick questions.
Why it matters
One of the first highly human-looking androids shown publicly, using air actuators under silicone skin.
Real-world use
Four Actroids guided visitors and hosted a stage at Expo 2005 in Aichi; a rental-only DER version followed in June 2005.
Maker
Osaka UniversityUniversity lab · Suita, Osaka, JapanUniversity research lab; ERICA was developed within the JST ERATO Ishiguro Symbiotic Human-Robot Interaction Project.
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
Actroid (Repliee Q1) has more joints than 74% of the 236 other humanoids that publish a joints. Bars show the 7 closest in date.
Not published by the maker: height, weight, speed, payload, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- 5,181 views of its Wikipedia article in the last 90 days (Actroid)
- 3 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Hands
- simple
- Movement
- Stationary · 42 joints
- Actuators & motors
- Pneumatic (air) actuators, mostly in the upper body: 42 points of articulation on early models, 47 on later ones; compressed air supplied from outside the robot.
- Sensors & vision
- Touch sensors; microphones with noise filtering; floor sensors and omnidirectional vision for eye contact.
- Compute
- Most of the computing that runs its AI sits outside the robot; voice comes from external speakers.
- Materials & build
- Realistic silicone skin.
- AI & software
- Speech recognition and scripted AI responses; can learn movements by tracking reflective markers on a person.
- Other details
- Developed at Osaka University and manufactured by Kokoro, Sanrio's animatronics division.
Named suppliers:Kokoro
Lineage
Every Osaka University (Hiroshi Ishiguro) and Kokoro Co. humanoid in order.
 DB (Dynamic Brain)2000Retired
 Robovie2001Retired
 Actroid (Repliee Q1)2003Retired
- No public photo yetWe only show photos we're allowed to useCB2 (Child-robot with Biomimetic Body)2006Retired
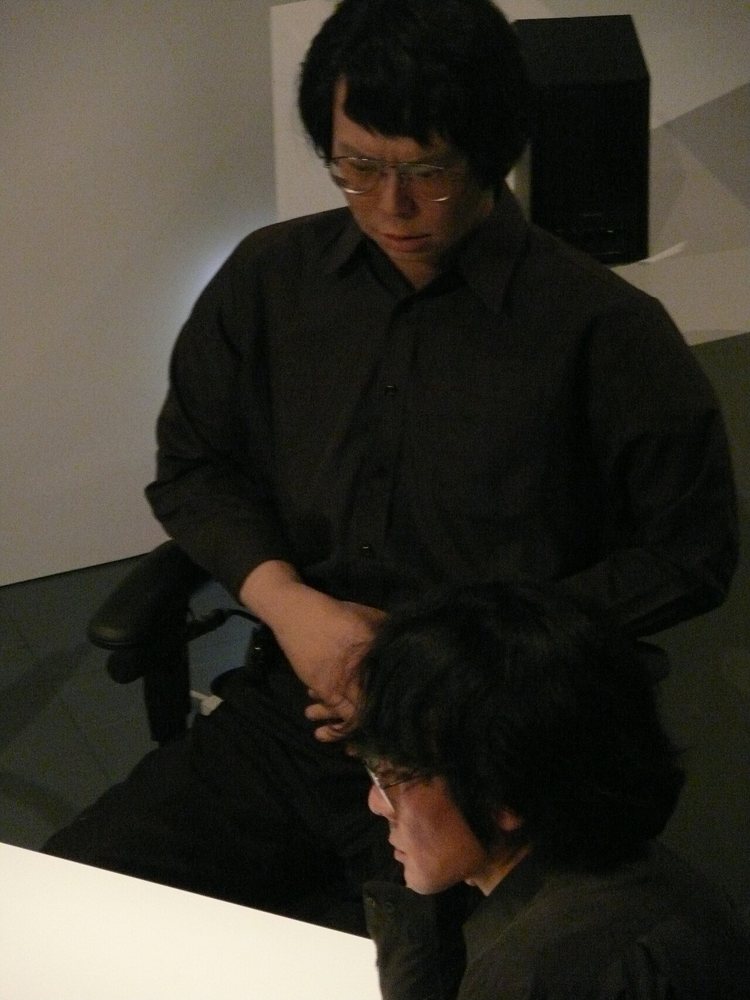 Geminoid HI-12006Retired
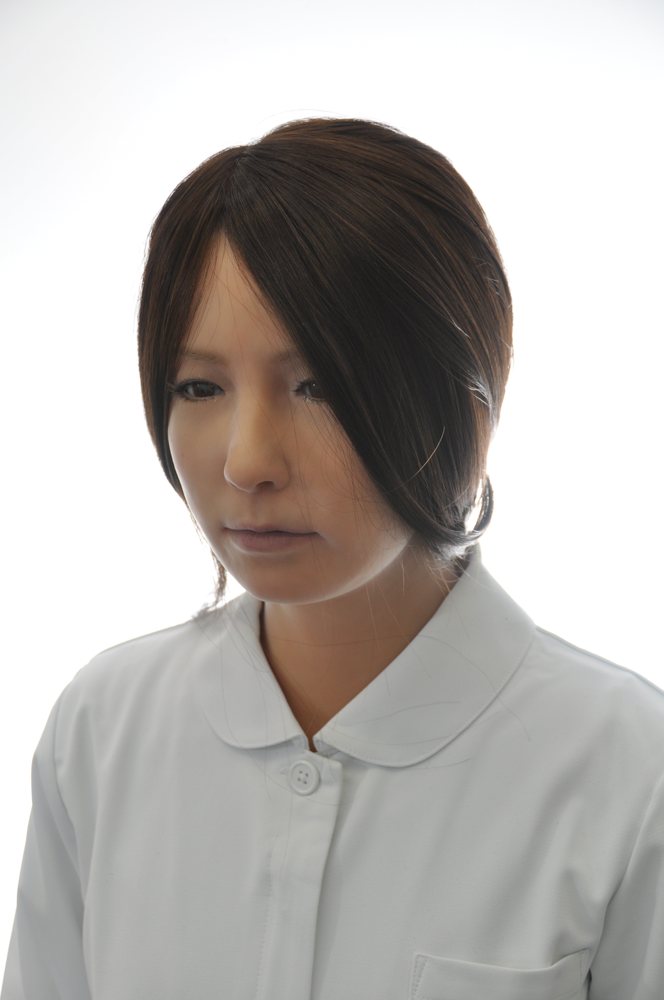 Geminoid F2010Retired
- No public photo yetWe only show photos we're allowed to usePneuborn2011Retired
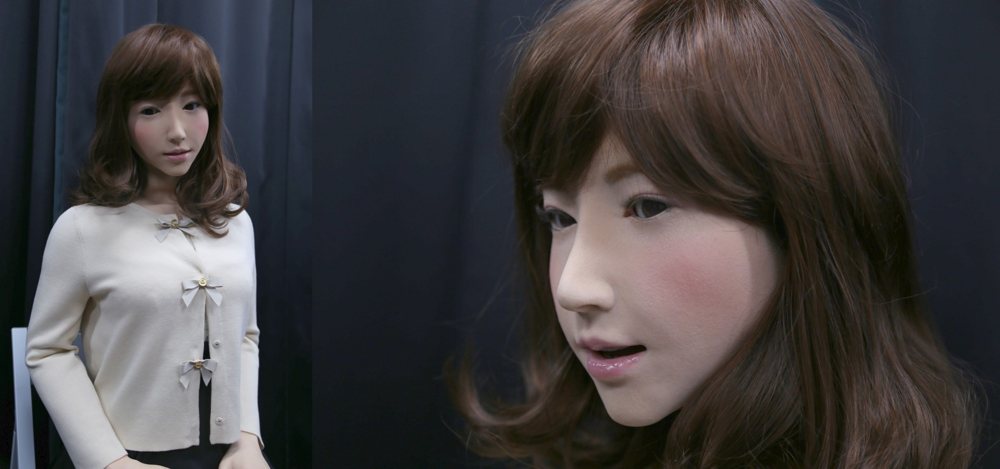 ERICA2015Research
- No public photo yetWe only show photos we're allowed to useAlter 32019Research
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Sold or delivered
- DER version offered for rental only from June 2005
- Where it is sold or used
- Japan
News
The latest 3, newest first. Summaries are ours; tap through for the original.
- Actroid-DER series and history
Kokoro introduced the Actroid-DER as a rental model.
Kokoro Company Ltd. - Actroid-DER series and history
The Actroid-Repliee Q1 model was developed at Osaka University.
Kokoro Company Ltd. - Actroid debuts at the International Robot Exhibition
Kokoro dates Actroid’s International Robot Exhibition debut to November 2003.
Kokoro Company Ltd.
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | Actroid (Repliee Q1)Osaka University (Hiroshi Ishiguro) and Kokoro Co. | No public photo yetWe only show photos we're allowed to useWE-4RIIWaseda University (Atsuo Takanishi lab)Same job: social · Both fixed in place · Both past robots | No public photo yetWe only show photos we're allowed to useBARTHOCBielefeld UniversitySame job: social · Both fixed in place · Both past robots | No public photo yetWe only show photos we're allowed to useEveR-2 MuseKorea Institute of Industrial Technology (KITECH)Same job: entertainment · Both fixed in place · Both past robots |
|---|---|---|---|---|
| First shown | 2003-11 | 2004 | 2005 | 2006 |
| Status | Retired | Retired | Retired | Retired |
| Height | — | 97 cm | — | 170 cm |
| Weight | — | 59.3 kg | — | 61 kg |
| Joints | 42 | 59 | — | 23 |
| Speed | — | — | — | — |
| Payload | — | — | — | — |
| Battery | — | — | — | — |
| Price | — | — | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use