JSK Laboratory, University of Tokyo · research humanoid
Kengoro
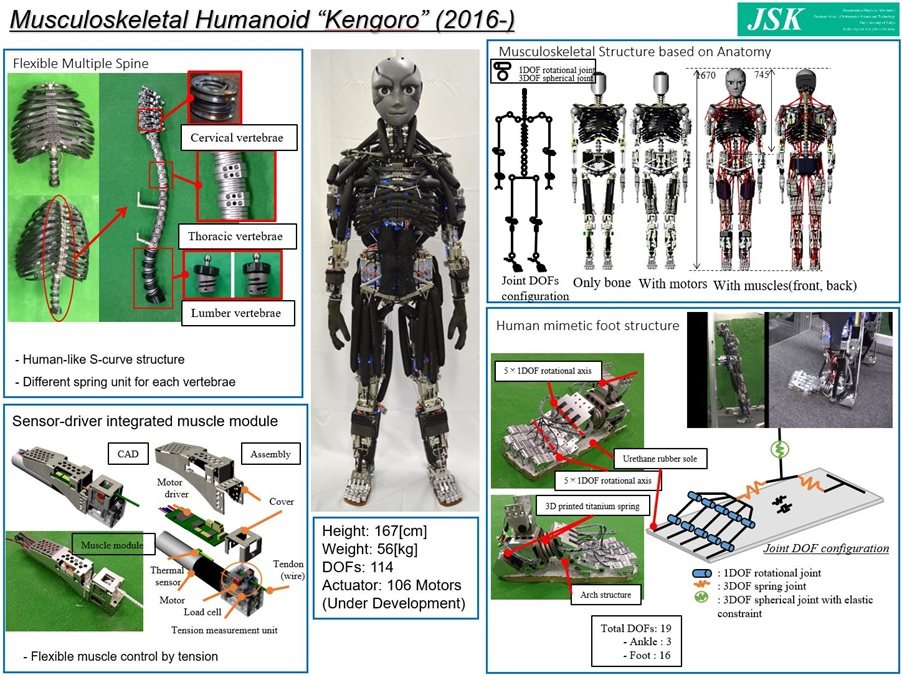
A musculoskeletal humanoid with artificial muscles and bones, 1.7 m and 56 kg, that could do push-ups for 11 minutes thanks to evaporative cooling.
- Price
- —Not published
- Height
- 170 cmTaller than 59%
- Weight
- 56 kgHeavier than 42%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
Cooled its 108 motors by 'sweating' water through a porous laser-sintered skeleton.
Real-world use
University of Tokyo JSK Lab
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
Kengoro is taller than 59% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
Kengoro is heavier than 42% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
Not published by the maker: speed, payload, joints, battery, price.
What it has been shown doing
We checked public videos and press for Kengoro and found no clear demo of the skills we track yet.
Public attention
How much public attention Kengoro gets, from open data.
- No Wikipedia article of its own yet
- 1 news story from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Hands
- simple
- Movement
- Walks on legs
- Actuators & motors
- 108 motors in a musculoskeletal (muscle-like) layout.
- Materials & build
- Aluminium frame laser-sintered from powder, with porosity tuned from solid to porous so the skeleton carries water.
- Other details
- Passive evaporative cooling ('sweating'): deionized water flows through microchannels in the frame and seeps out near the motors; about a cup lasts half a day, roughly three times better than air cooling. Did push-ups for 11 minutes without overheating. 1.7 m, 56 kg.
Lineage
Every University of Tokyo JSK Lab humanoid in order.
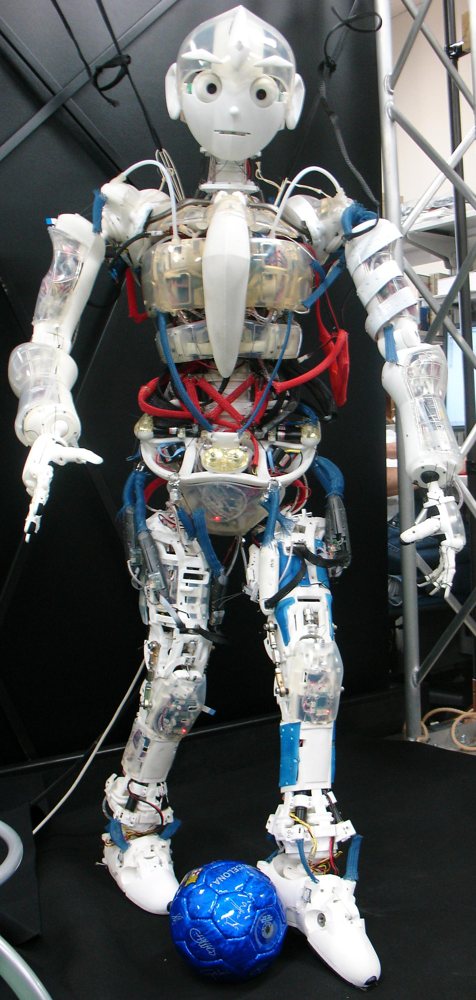
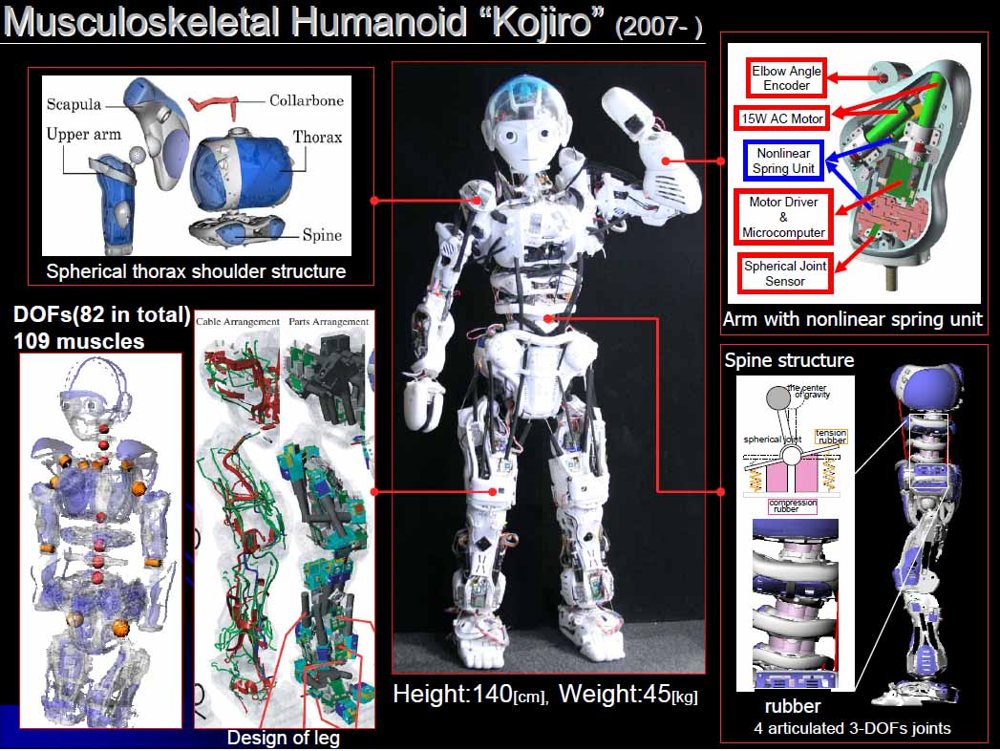
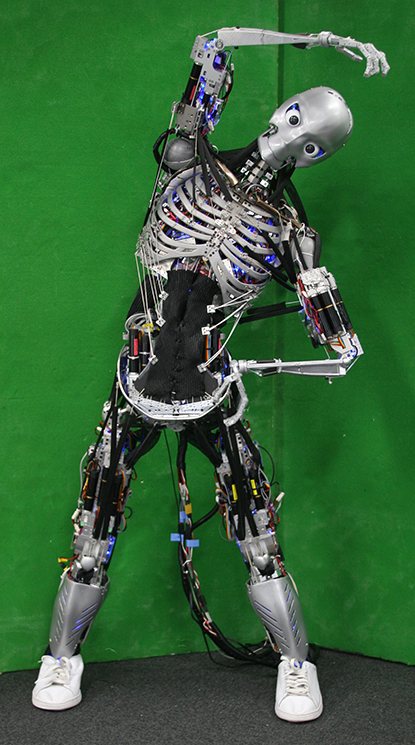
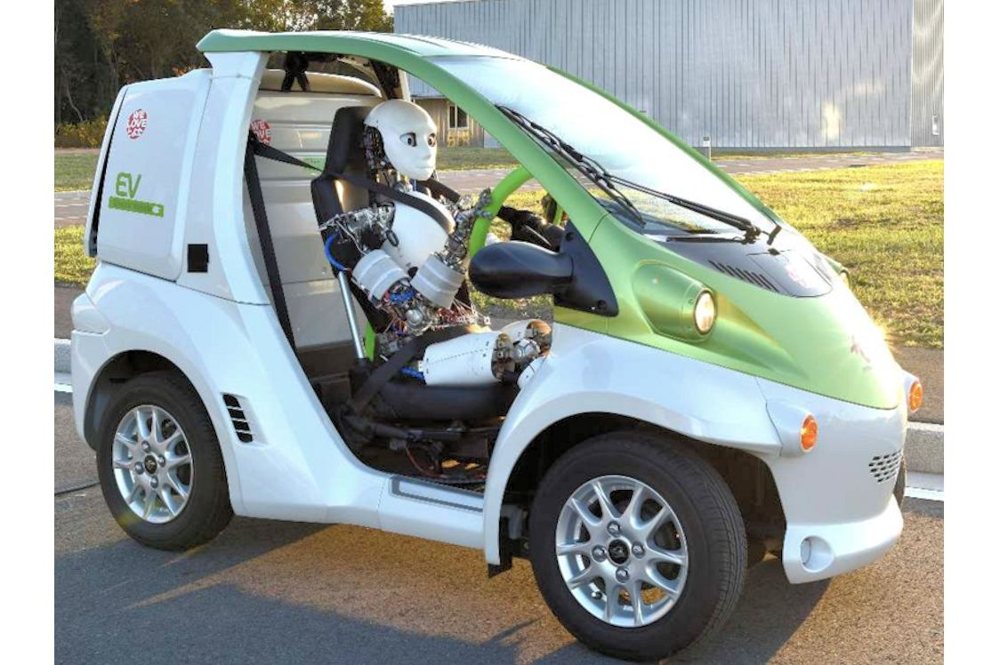
Watch Kengoro
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- research prototype
- Sold or delivered
- never sold
- Where it is sold or used
- Japan
- Customers and pilots
- University of Tokyo JSK Lab
News
The latest 1, newest first. Summaries are ours; tap through for the original.
- Sweating robot at IROS 2016
JSK presented Kengoro's water-cooled skeleton at IROS 2016 in Daejeon.
IEEE Spectrum
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. Few robots match closely, so these are the nearest matches. How we choose
| Measure | KengoroUniversity of Tokyo JSK Lab | 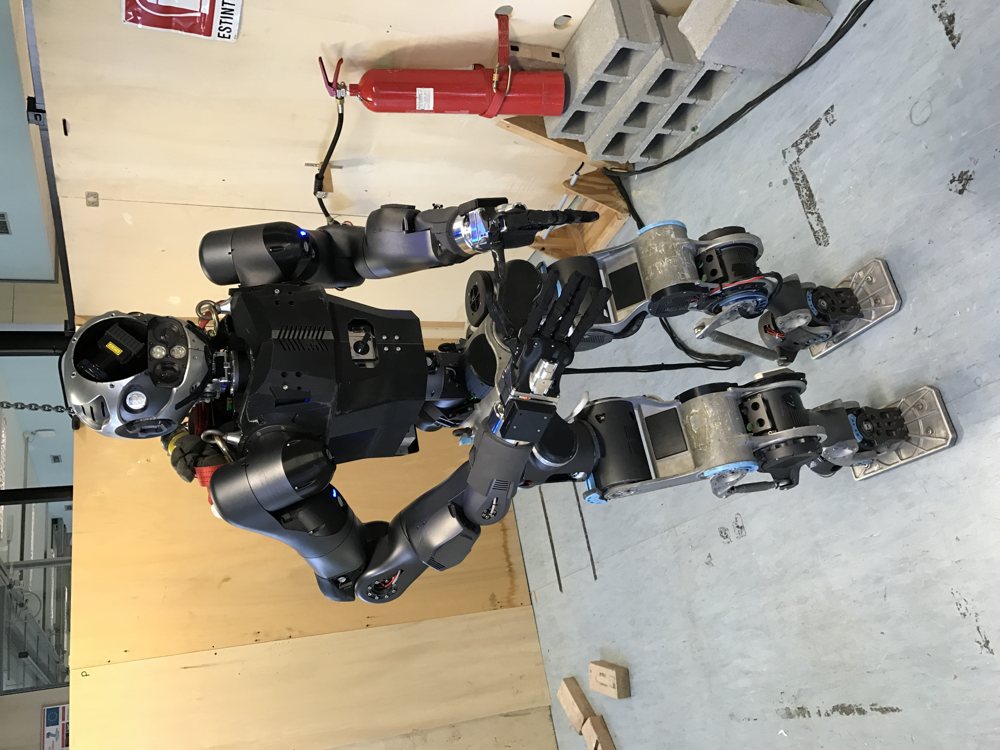 WALK-MANIstituto Italiano di Tecnologia (IIT)Same job: research · Both walk · Both research platforms · Similar size | 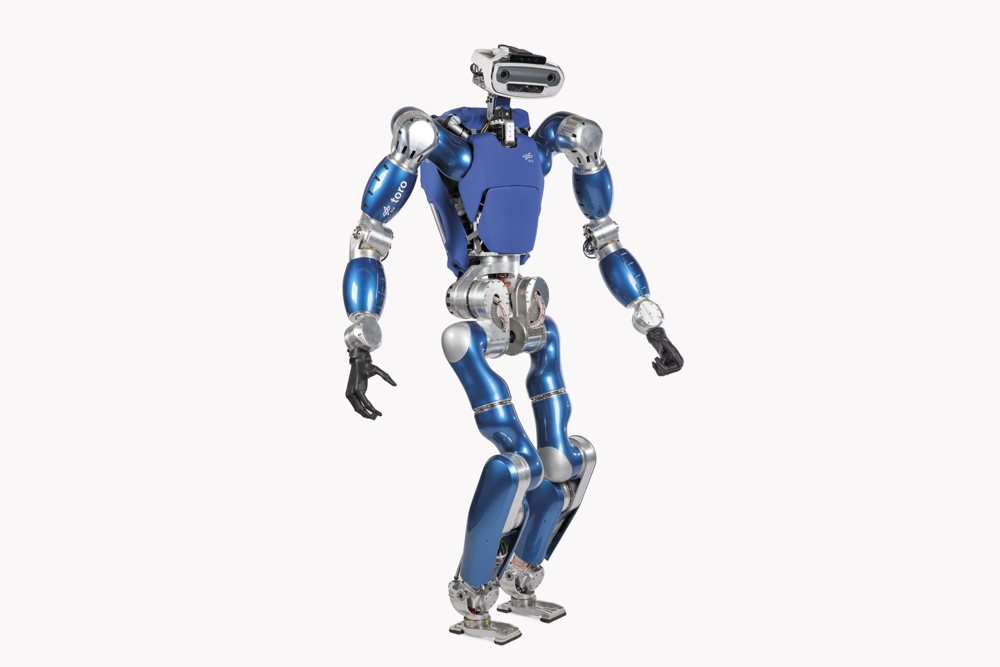 TOROGerman Aerospace Center (DLR)Same job: research · Both walk · Both research platforms · Similar size | 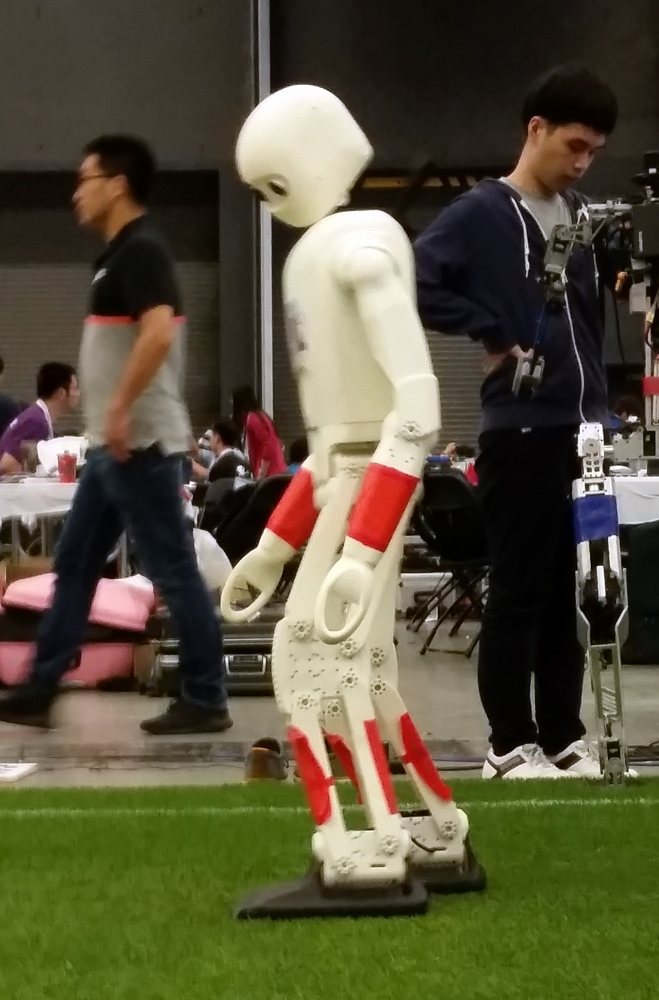 NimbRo-OP2University of Bonn (Autonomous Intelligent Systems group)Same job: research · Both walk · Both research platforms |
|---|---|---|---|---|
| First shown | 2016-10 | 2015-06 | 2013-03-25 | 2017-07 |
| Status | Research | Research | Research | Research |
| Height | 170 cm | 185 cm | 174 cm | 135 cm |
| Weight | 56 kg | 120 kg | 76 kg | 18 kg |
| Joints | — | — | 39 | 18 |
| Speed | — | — | 1.8 km/h | — |
| Payload | — | — | 10 kg | — |
| Battery | — | — | 1 h | — |
| Price | — | — | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use