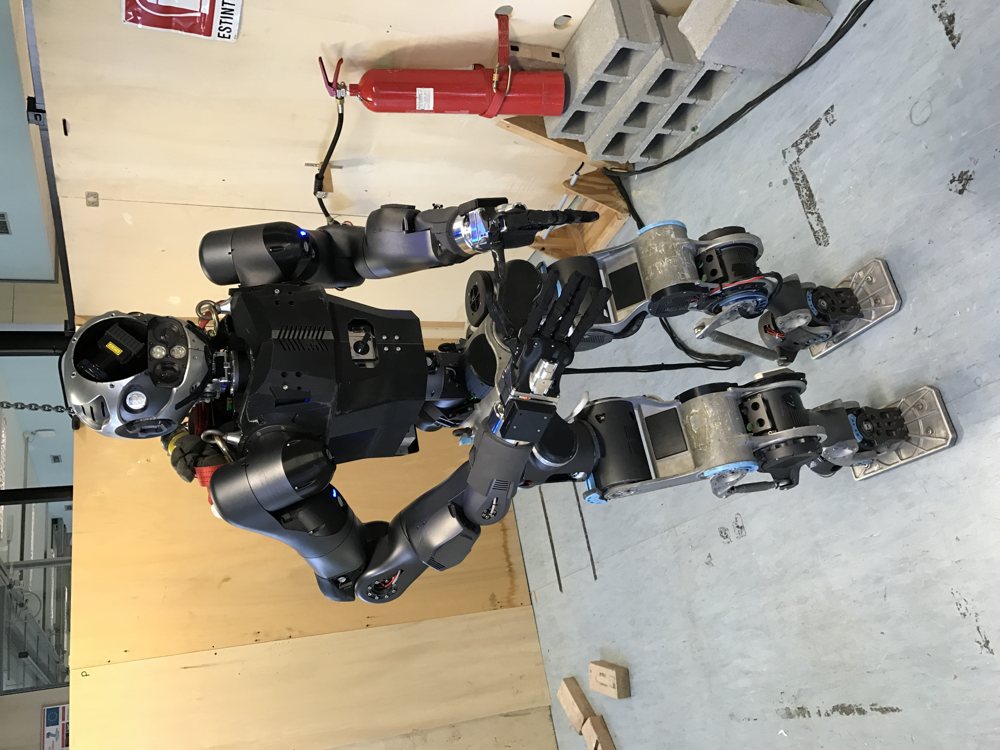
Istituto Italiano di Tecnologia (IIT) · research humanoid
WALK-MAN
An EU-funded disaster-response humanoid, 1.85 m tall and about 120 kg with its battery backpack. It retired early from the 2015 DRC Finals with a battery problem; IIT kept developing it afterward.
- Price
- —Not published
- Height
- 185 cmTaller than 94%
- Weight
- 120 kgHeavier than 88%
- Payload
- —Not published
- Speed
- —Not published
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
Europe's main full-size entry at the DRC Finals; a slimmer 2018 version (about 102 kg) was shown fighting fires.
Real-world use
No customers or deployments reported yet.
Timeline
- First shown
- 2015-06
- Released
- Not yet
Maker
Istituto Italiano di Tecnologia (IIT)Government lab · founded 2003 · Genoa, ItalyAbout EUR 90 million a year from the Italian government; RobotCub received EUR 8.5 million from the European Commission
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
WALK-MAN is taller than 94% of the 305 other humanoids that publish a height. Bars show the 7 closest in date.
WALK-MAN is heavier than 88% of the 277 other humanoids that publish a weight. Bars show the 7 closest in date.
Not published by the maker: speed, payload, joints, battery, price.
What it has been shown doing
We checked public videos and press for WALK-MAN and found no clear demo of the skills we track yet.
Public attention
How much public attention WALK-MAN gets, from open data.
- No Wikipedia article of its own yet
- 2 news stories from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Movement
- Walks on legs
- Actuators & motors
- Electric motors with built-in joint elasticity and custom high-power drives (several kW peak per joint); leg joints up to 320 Nm, shoulder joints up to 140 Nm; position, torque and impedance control at up to 5 kHz (IEEE Spectrum).
- Hands
- Human-inspired hands designed to be robust and adaptable enough to grip and use hand tools (CORDIS).
- Sensors & vision
- Joint torque sensing with thermal and fatigue monitoring; head with stereo vision, a rotating 3D laser scanner, a depth camera and colour cameras.
- Battery & power
- Embedded battery for about one hour of autonomous operation (CORDIS).
- AI & software
- ROS and YARP; can run autonomously or be commanded by a pilot from an operator station.
- Other details
- 1.85 m tall, 100-120 kg with backpack; designed and built in 10 months (March 2014 - January 2015) by a 19-person team, mostly from IIT. EU project 611832 with the University of Pisa, EPFL, UCLouvain and KIT.
Named suppliers:ROS (Open Robotics)
Lineage
Every Istituto Italiano di Tecnologia (IIT) humanoid in order.
 iCub2008Research
- No public photo yetWe only show photos we're allowed to useCOMAN (COmpliant huMANoid)2012Retired
- WALK-MAN2015Research
 R12016Prototype
 ALTER-EGO2017Pilot use
 iCub32022Research
 ergoCub2023Prototype
 iRonCub32025Research
Istituto Italiano di Tecnologia (IIT) also makes 3 machines. See every Istituto Italiano di Tecnologia (IIT) robot
Watch WALK-MAN
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Built
- One prototype.
- Sold or delivered
- Never sold.
- Where it is sold or used
- Italy; competed in the United States
News
The latest 2, newest first. Summaries are ours; tap through for the original.
- WALK-MAN competes at DRC Finals
IIT's humanoid took part in the DARPA Robotics Challenge Finals in California.
CORDIS, European Commission - IEEE profiles WALK-MAN
IEEE Spectrum detailed the electric, compliant humanoid ahead of the Finals.
IEEE Spectrum
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | WALK-MANIstituto Italiano di Tecnologia (IIT) | No public photo yetWe only show photos we're allowed to useJAXONUniversity of Tokyo JSK Lab (team NEDO-JSK)Same job: research · Both walk · Both research platforms · Similar size | 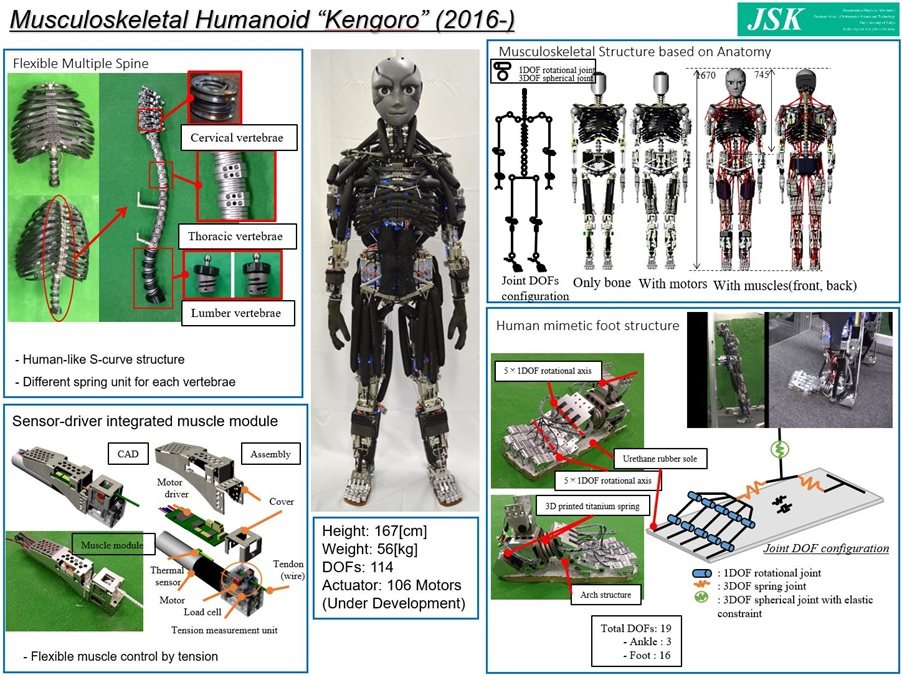 KengoroUniversity of Tokyo JSK LabSame job: research · Both walk · Both research platforms · Similar size | 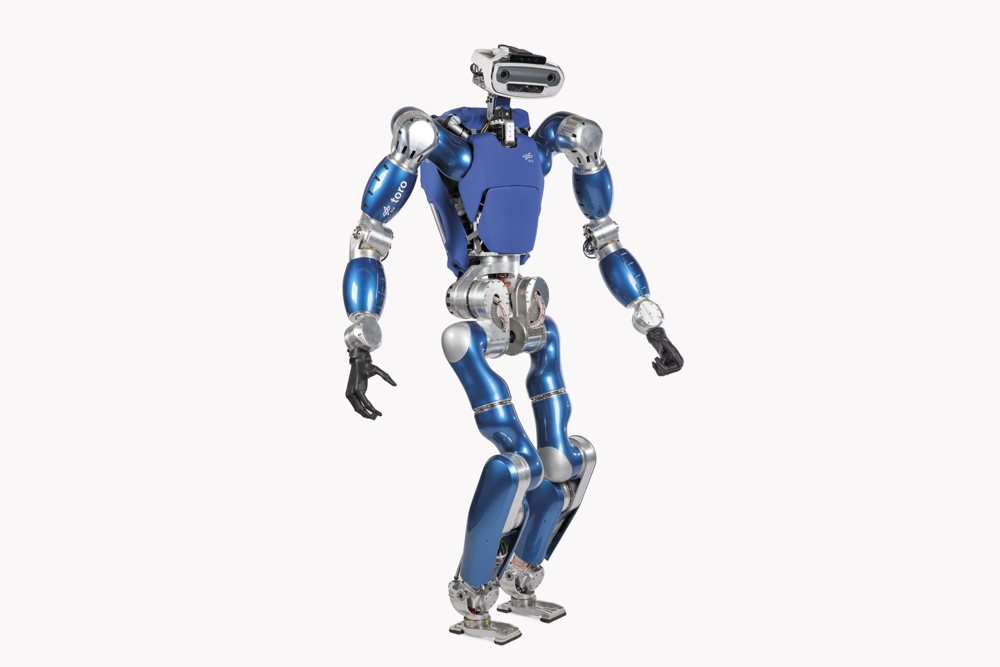 TOROGerman Aerospace Center (DLR)Same job: research · Both walk · Both research platforms · Similar size |
|---|---|---|---|---|
| First shown | 2015-06 | 2015-06 | 2016-10 | 2013-03-25 |
| Status | Research | Research | Research | Research |
| Height | 185 cm | 188 cm | 170 cm | 174 cm |
| Weight | 120 kg | 110 kg | 56 kg | 76 kg |
| Joints | — | 33 | — | 39 |
| Speed | — | — | — | 1.8 km/h |
| Payload | — | — | — | 10 kg |
| Battery | — | — | — | 1 h |
| Price | — | — | — | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use