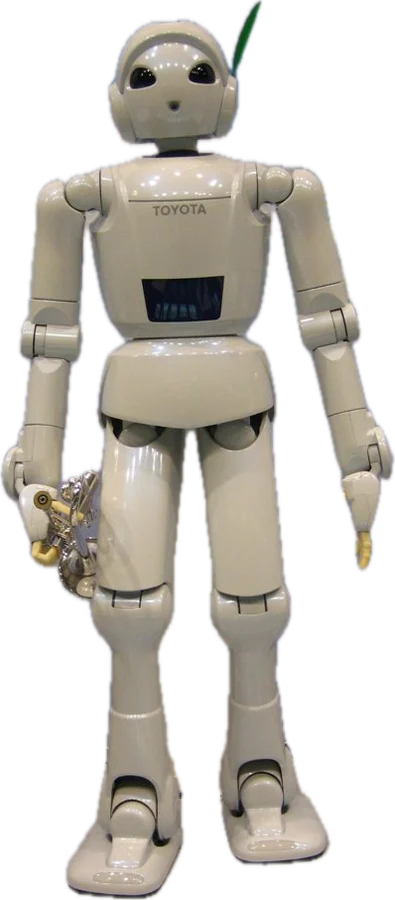
Toyota Research Institute · research humanoid
Toyota Partner Robot
running humanoid
An updated bipedal Partner Robot shown running at 7 km/h on flat ground in July 2009.
- Price
- —Not published
- Height
- —Not published
- Weight
- —Not published
- Payload
- —Not published
- Speed
- 7.0 km/hFaster than 75%
- Battery
- —Not published
Not sure this is the one? Find the best robot for your job Starts with: research and teaching. Five more quick questions.
Why it matters
Ran at 7 km/h, faster than ASIMO's 6 km/h at the time.
Real-world use
No customers or deployments reported yet.
Timeline
- First shown
- 2009-07
- Released
- Not yet
Maker
Toyota Research InstituteCompany · founded 2016 · Los Altos, California, United StatesToyota subsidiary; launched with $1 billion over five years.
How it stacks up
Against other humanoids that publish the figure. Pick a measure.
Toyota Partner Robot (running humanoid) is faster than 75% of the 122 other humanoids that publish a speed. Bars show the 7 closest in date.
Not published by the maker: height, weight, payload, joints, battery, price.
Public attention
A historic robot: no longer sold or in use, so it is not ranked against current humanoids.
- 756 views of its Wikipedia article in the last 90 days (Toyota Partner Robot)
- 1 news story from reputable press listed on this page
Measures how much people read and write about a robot, not how good it is. Measured 2026-10-13; same method for every robot. How it is measured
What’s inside
The parts the company has talked about publicly.
- Hands
- dexterous
- Movement
- Walks on legs
- Other details
- Toyota's July 2009 video showed the humanoid running at about 7 km/h; walking and running worked only on flat ground.
Lineage
Every Toyota Motor Corporation humanoid in order.
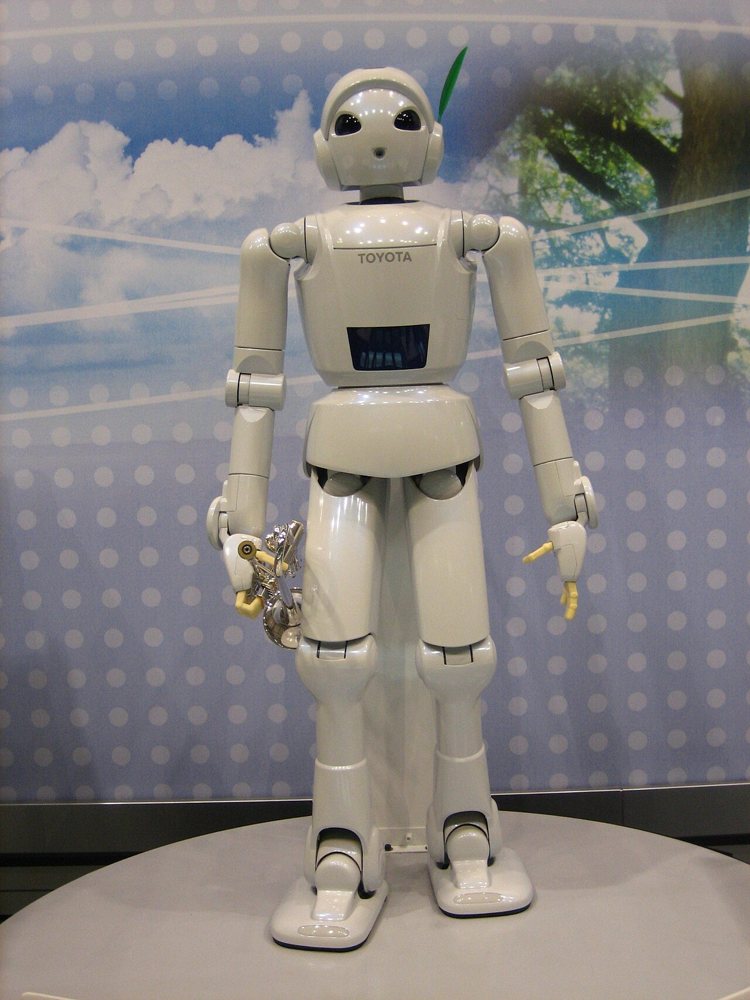 Toyota Partner Robot (walking type)2004Retired
 Toyota Partner Robot (violin-playing)2007Retired
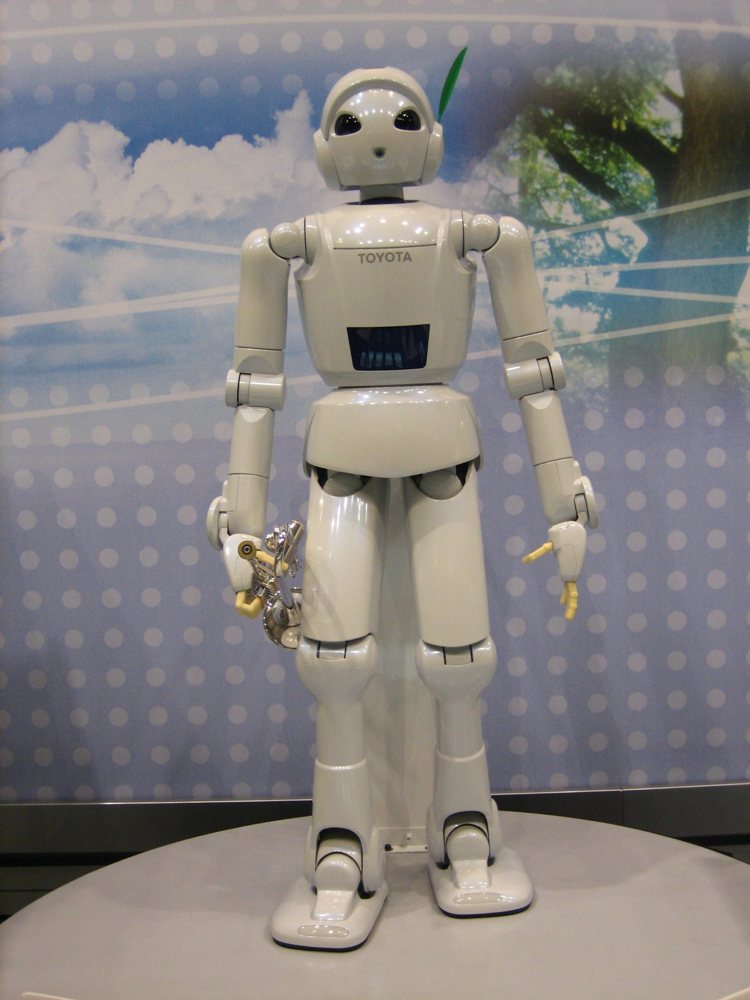 Toyota Partner Robot (running humanoid)2009Retired
 Human Support Robot (HSR)2012Research
 Kirobo2013Retired
 T-HR32017Research
- No public photo yetWe only show photos we're allowed to useCUE (first generation)2018Retired
- No public photo yetWe only show photos we're allowed to useCUE32019Retired
 CUE62022Research
 Punyo2024Research
 CUE72026Research
Toyota Research Institute also makes 1 machine and 1 vehicle. See every Toyota Research Institute robot
Made, sold and where
Unit counts are usually company figures; analysts often disagree.
- Price
- Not published
- How to get one
- No official buying page found
- Sold or delivered
- Never sold.
- Where it is sold or used
- Japan
News
The latest 1, newest first. Summaries are ours; tap through for the original.
- Toyota running robot
Runs at 7 km/h.
Engadget
Side by side with its peers
Picked by the same rules for every humanoid: another maker’s robot that moves the same way, is at the same stage and does at least one of the same main jobs, first shown within two years. Closer size and price rank higher. How we choose
| Measure | Toyota Partner Robot (running humanoid)Toyota Motor Corporation | 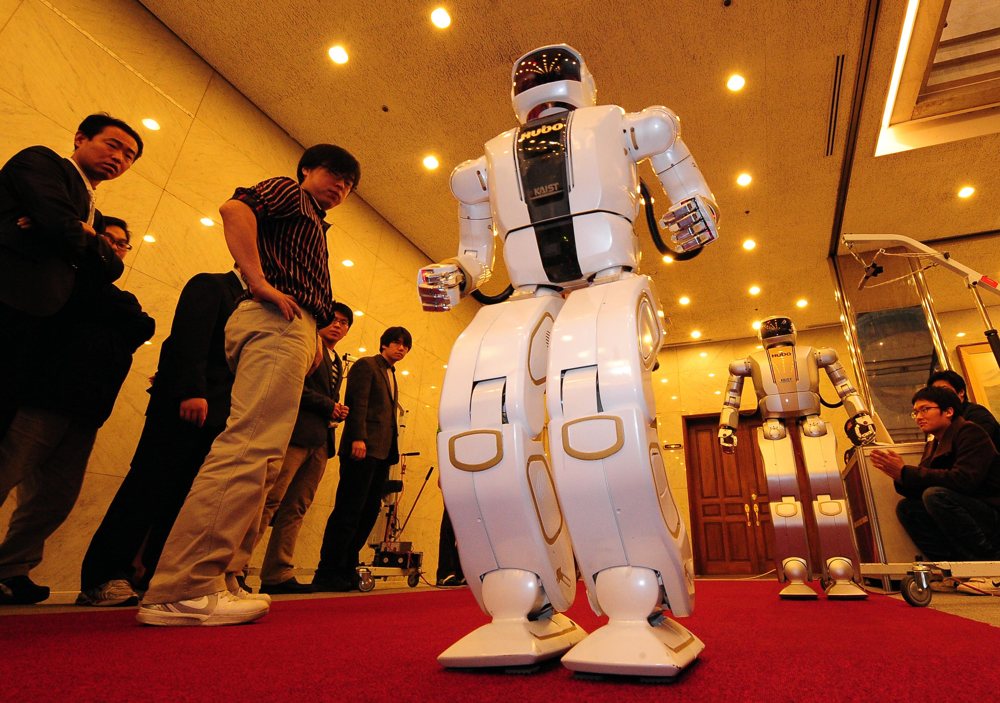 HUBO 2 (KHR-4)KAIST Hubo Lab (Jun-Ho Oh)Same job: research · Both walk · Both past robots | 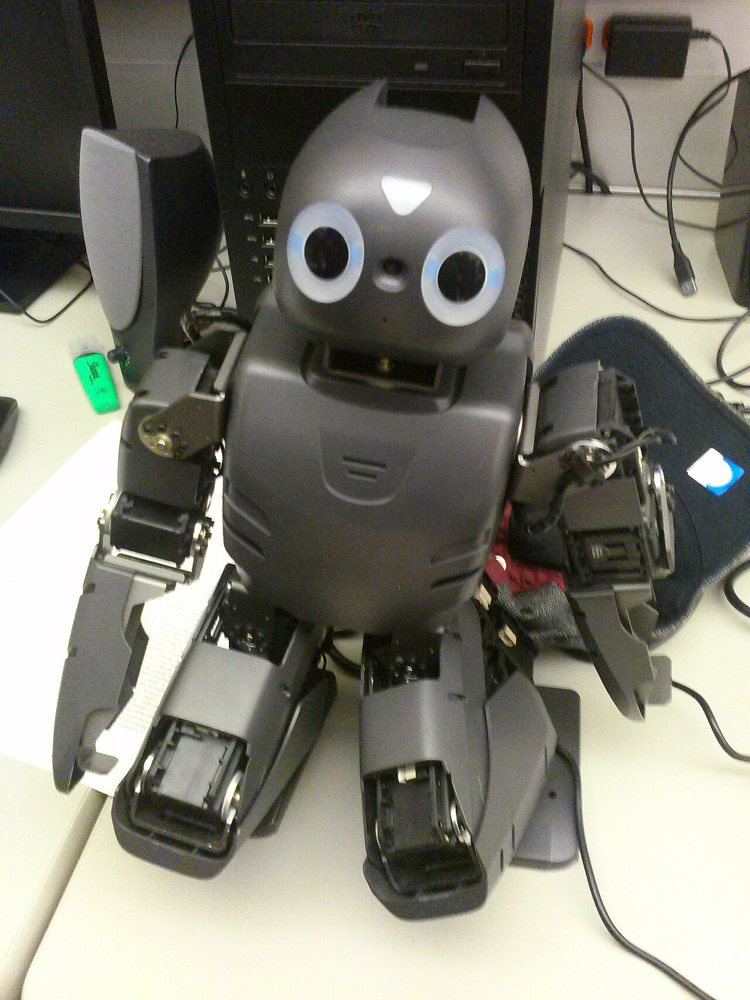 DARwIn-OPROBOTIS (with Virginia Tech, University of Pennsylvania and Purdue University)Same job: research · Both walk · Both past robots | 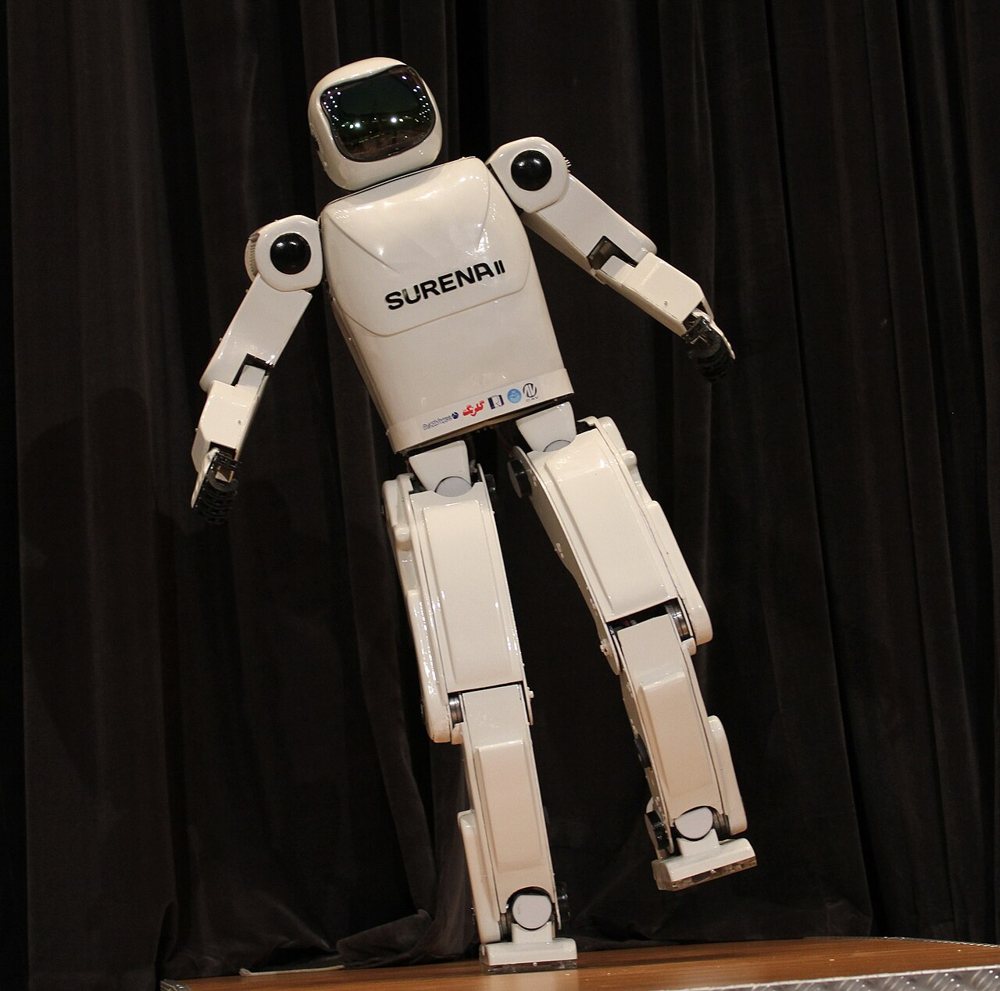 Surena IIUniversity of Tehran, Center for Advanced VehiclesSame job: research · Both walk · Both past robots |
|---|---|---|---|---|
| First shown | 2009-07 | 2008 | 2010 | 2010-07-03 |
| Status | Retired | Discontinued | Discontinued | Retired |
| Height | — | 125 cm | 46 cm | 145 cm |
| Weight | — | 45 kg | 2.9 kg | 45 kg |
| Joints | — | 41 | 20 | 22 |
| Speed | 7 km/h | 3.6 km/h | 0.9 km/h | 0.1 km/h |
| Payload | — | — | — | — |
| Battery | — | 2 h | — | — |
| Price | — | $400,000 | $12,000 | — |
Sources
Figures come from press coverage. Every link below backs something on this page.
Photos and logos only identify each robot and its maker. Simbeing is not affiliated with, sponsored by or endorsing any company, and nothing here is advertising. Figures are for statistics only and are not advice of any kind. Terms of use